UAV research &
flight testing
These experiments show my work on control algorithms, simulation and flight hardware. Each video identifies whether it shows a simulation, a bench test or a flight test.
Explore the experimentsA route through constraints
An aircraft study
Look around
the airframe.
Drag to turn the Global Hawk model, or use the controls to inspect another angle.
Model by NASA / Michael D. CarbajalA visual aircraft study, alongside my UAV work.
 Global Hawk · drag sideways to turn
01 / HITL Testing
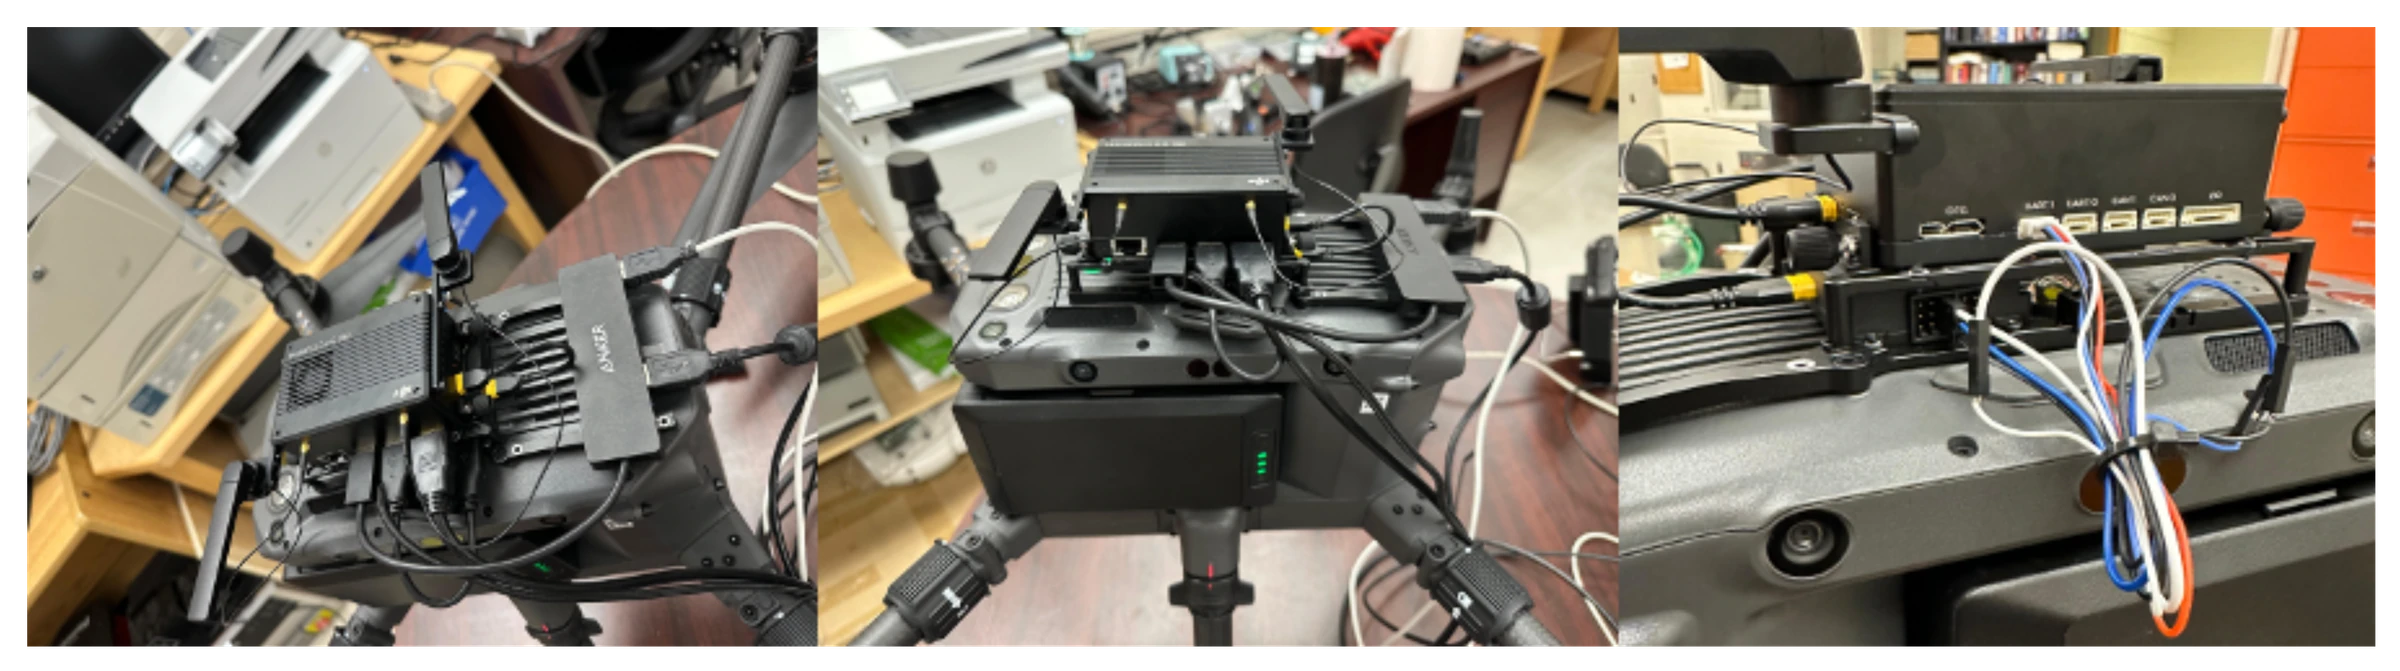
DJI M300 RTK - Hardware-in-the-Loop Testing
Testing trajectory tracking through DJI OSDK and the DJI Assistant 2 Simulator.
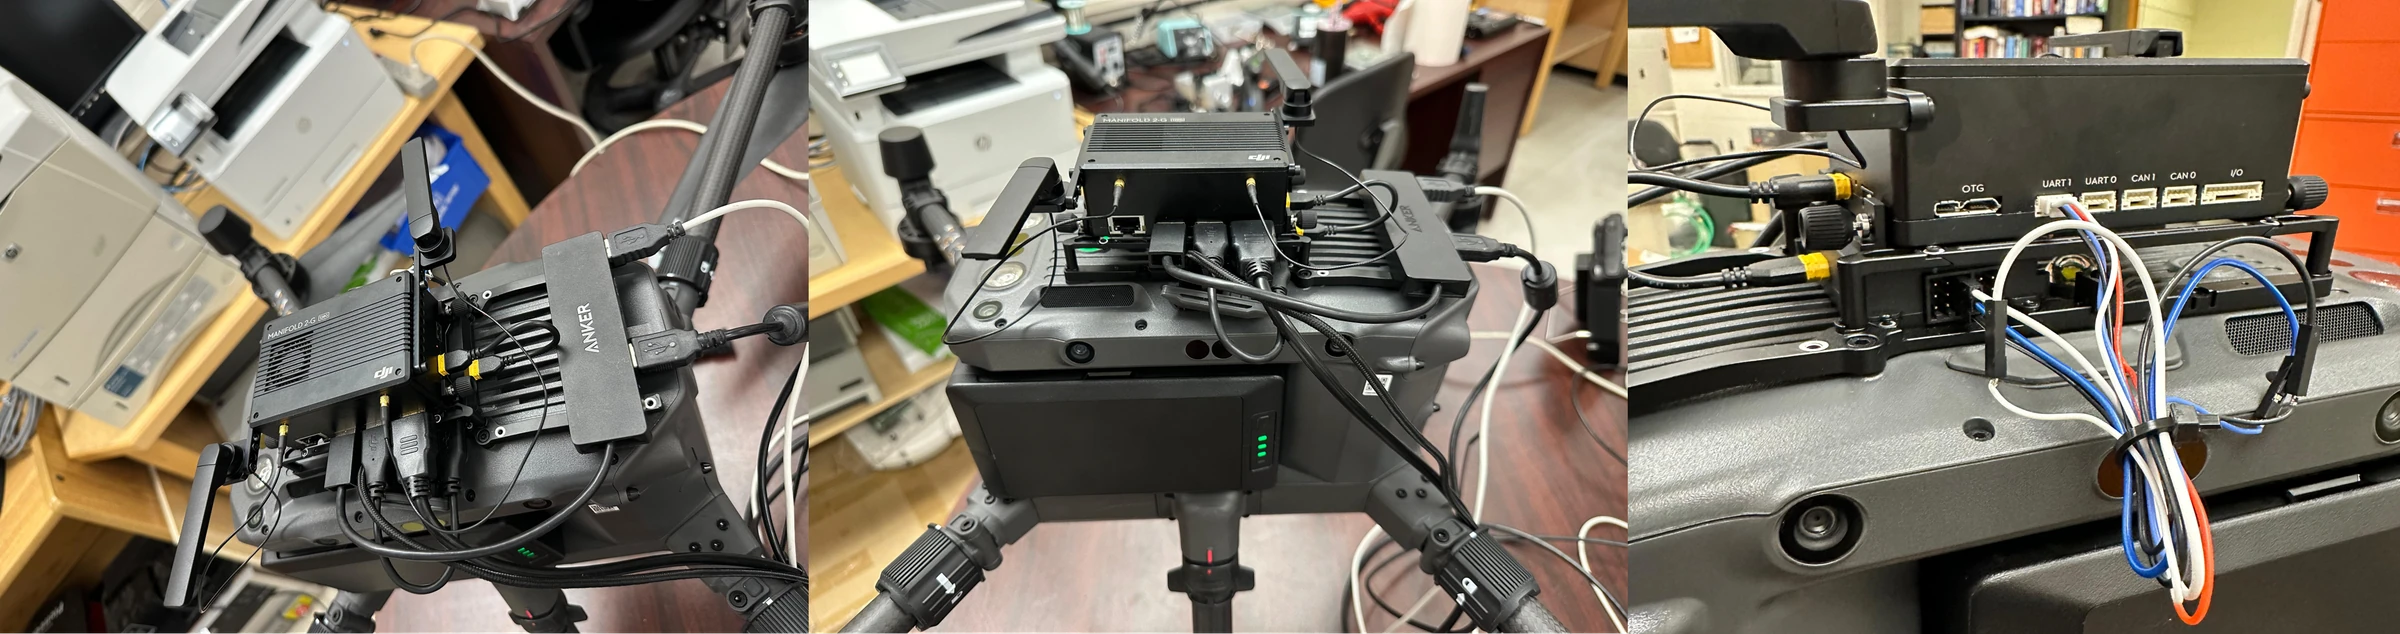
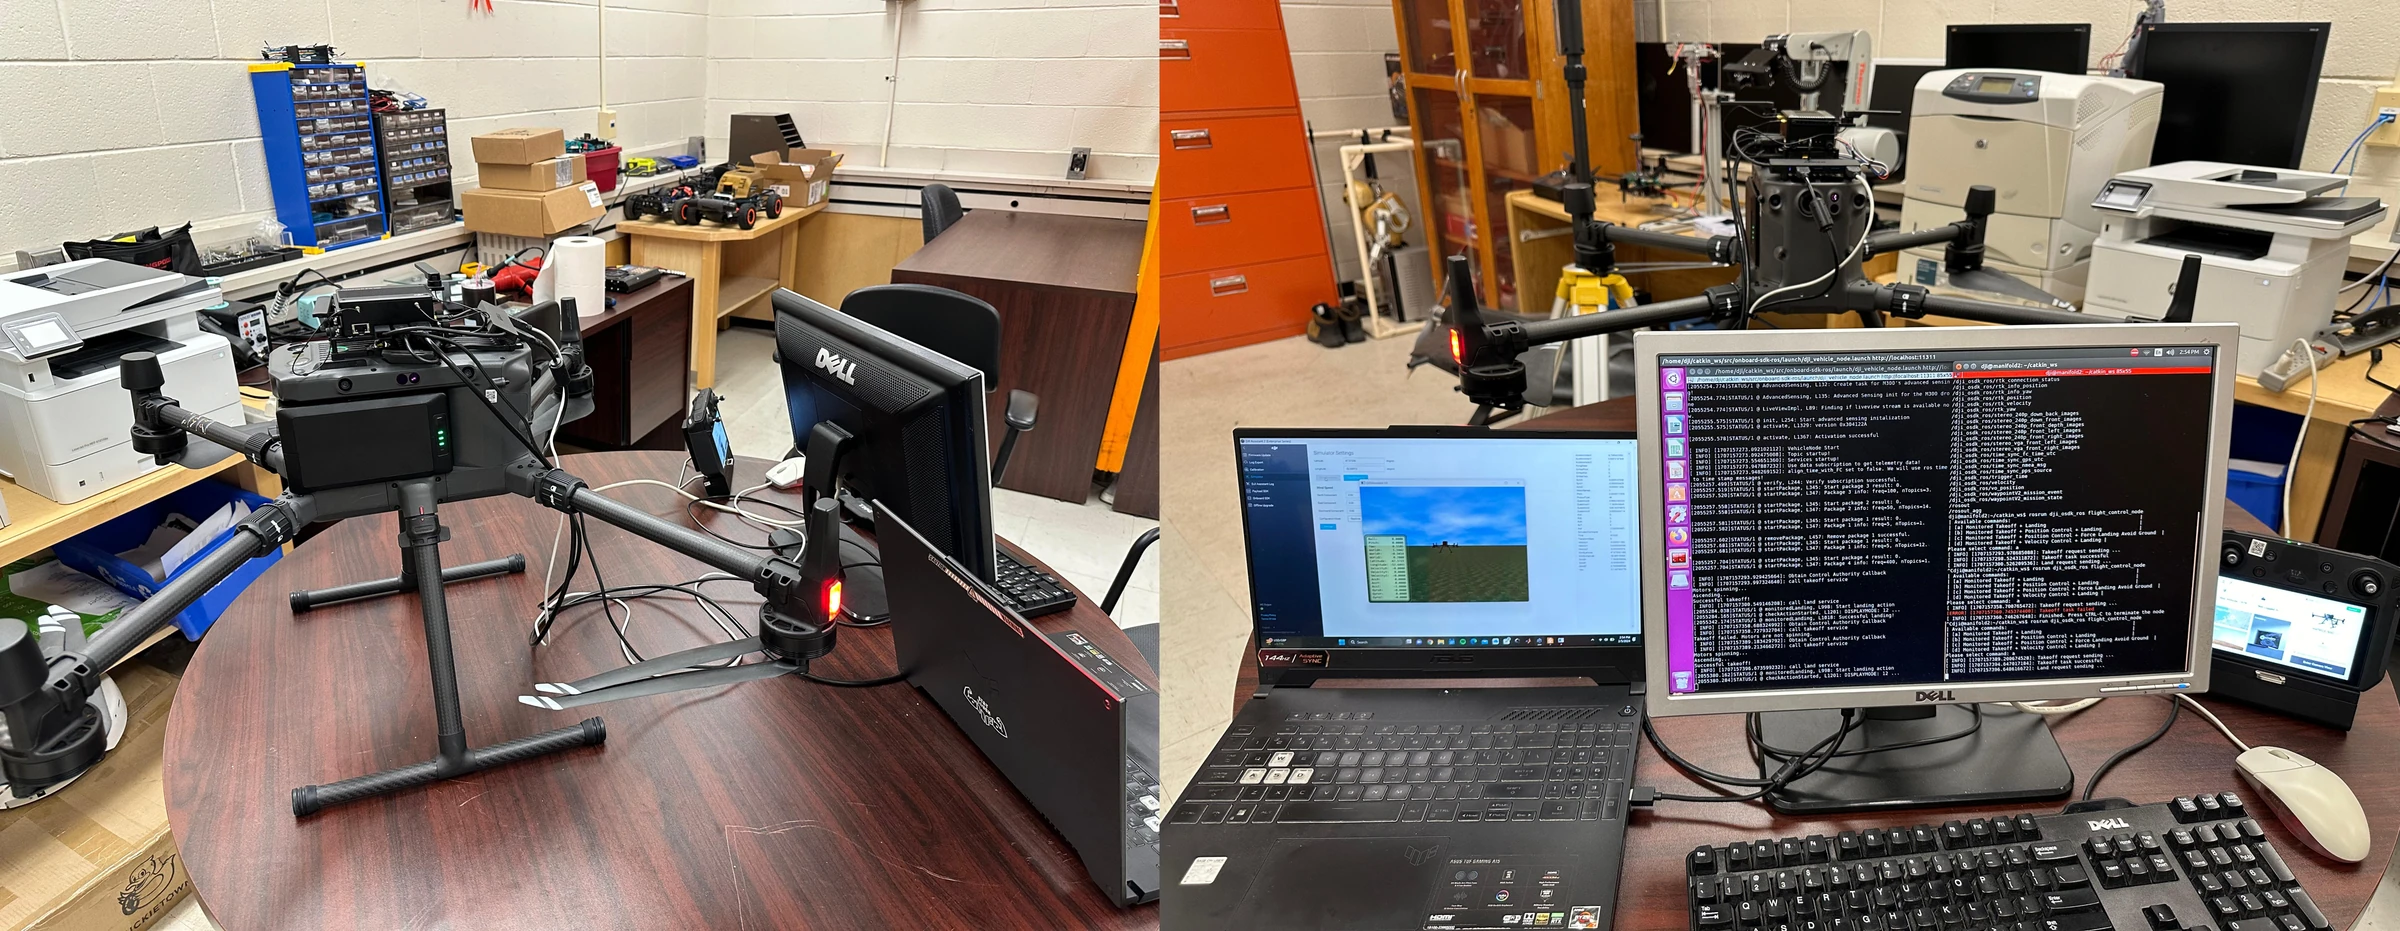
HITL Setup for Trajectory Planning and Control
Hardware-in-the-Loop (HITL) setup for trajectory planning and control algorithm testing on a DJI M300 using DJI OSDK and the DJI Assistant 2 Simulator.
Watch the simulationPID Circular Trajectory Tracking - HITL
PID implementation for circular trajectory tracking in a Hardware-in-the-Loop setup for the DJI M300 drone using the DJI Assistant 2 Simulator and DJI OSDK.
Watch the simulationMPC Circular Trajectory Tracking - HITL
Model Predictive Control implementation for circular-trajectory tracking in a Hardware-in-the-Loop setup for the DJI M300.
Watch the simulation02 / Bench Testing
HummingBird Drone - Motion Capture
Bench testing with OptiTrack motion capture for position and attitude feedback.
Bench Testing in OptiTrack Motion-Capture Environment
Bench testing of the HummingBird drone in a controlled OptiTrack motion-capture environment for position and attitude feedback testing.
Watch the bench test03 / 6-DOF Simulation
UAV Lateral Flight Controller
Lateral-controller testing in a nonlinear 6-DOF aircraft model. The Cessna shape is used for visualization.
UAV Lateral Flight Controller Design and 6-DOF Nonlinear Simulation Demonstration
Roll maneuvers and rate tracking demonstration using lateral flight controllers designed with linear models, implemented on a nonlinear 6-DOF simulation.
Watch the simulation04 / Flight Testing
Parrot Drone - Advanced Control Algorithms
Altitude-hold and path-tracking experiments using ADRC, MPC and PID.
ADRC-Based Altitude-Hold Flight Testing
Active Disturbance Rejection Control (ADRC) implementation for an altitude-hold flight experiment on the Parrot drone.
Watch the flight testExplicit MPC-Based Altitude-Hold Flight Testing
Model Predictive Control (MPC) implementation for an altitude-hold flight experiment with constraint handling on the Parrot drone.
Watch the flight testPID-Based Altitude-Hold and Path-Tracking
Classical PID control for altitude-hold and path-tracking.
Watch the flight test05 / Flight Testing
Custom Quadrotor - APM 2.8
Hover and control testing with an APM 2.8 flight controller.
Flight Testing of a Quadrotor with APM 2.8 - PID
PID-based flight control testing on a custom quadrotor using the APM 2.8 flight controller, demonstrating stable hover and basic maneuvers.
Watch the flight testFlight Testing of a Quadrotor with APM 2.8 - Basic Testing
Basic flight testing and system validation of a quadrotor equipped with APM 2.8, focusing on motor response and attitude control.
Watch the flight test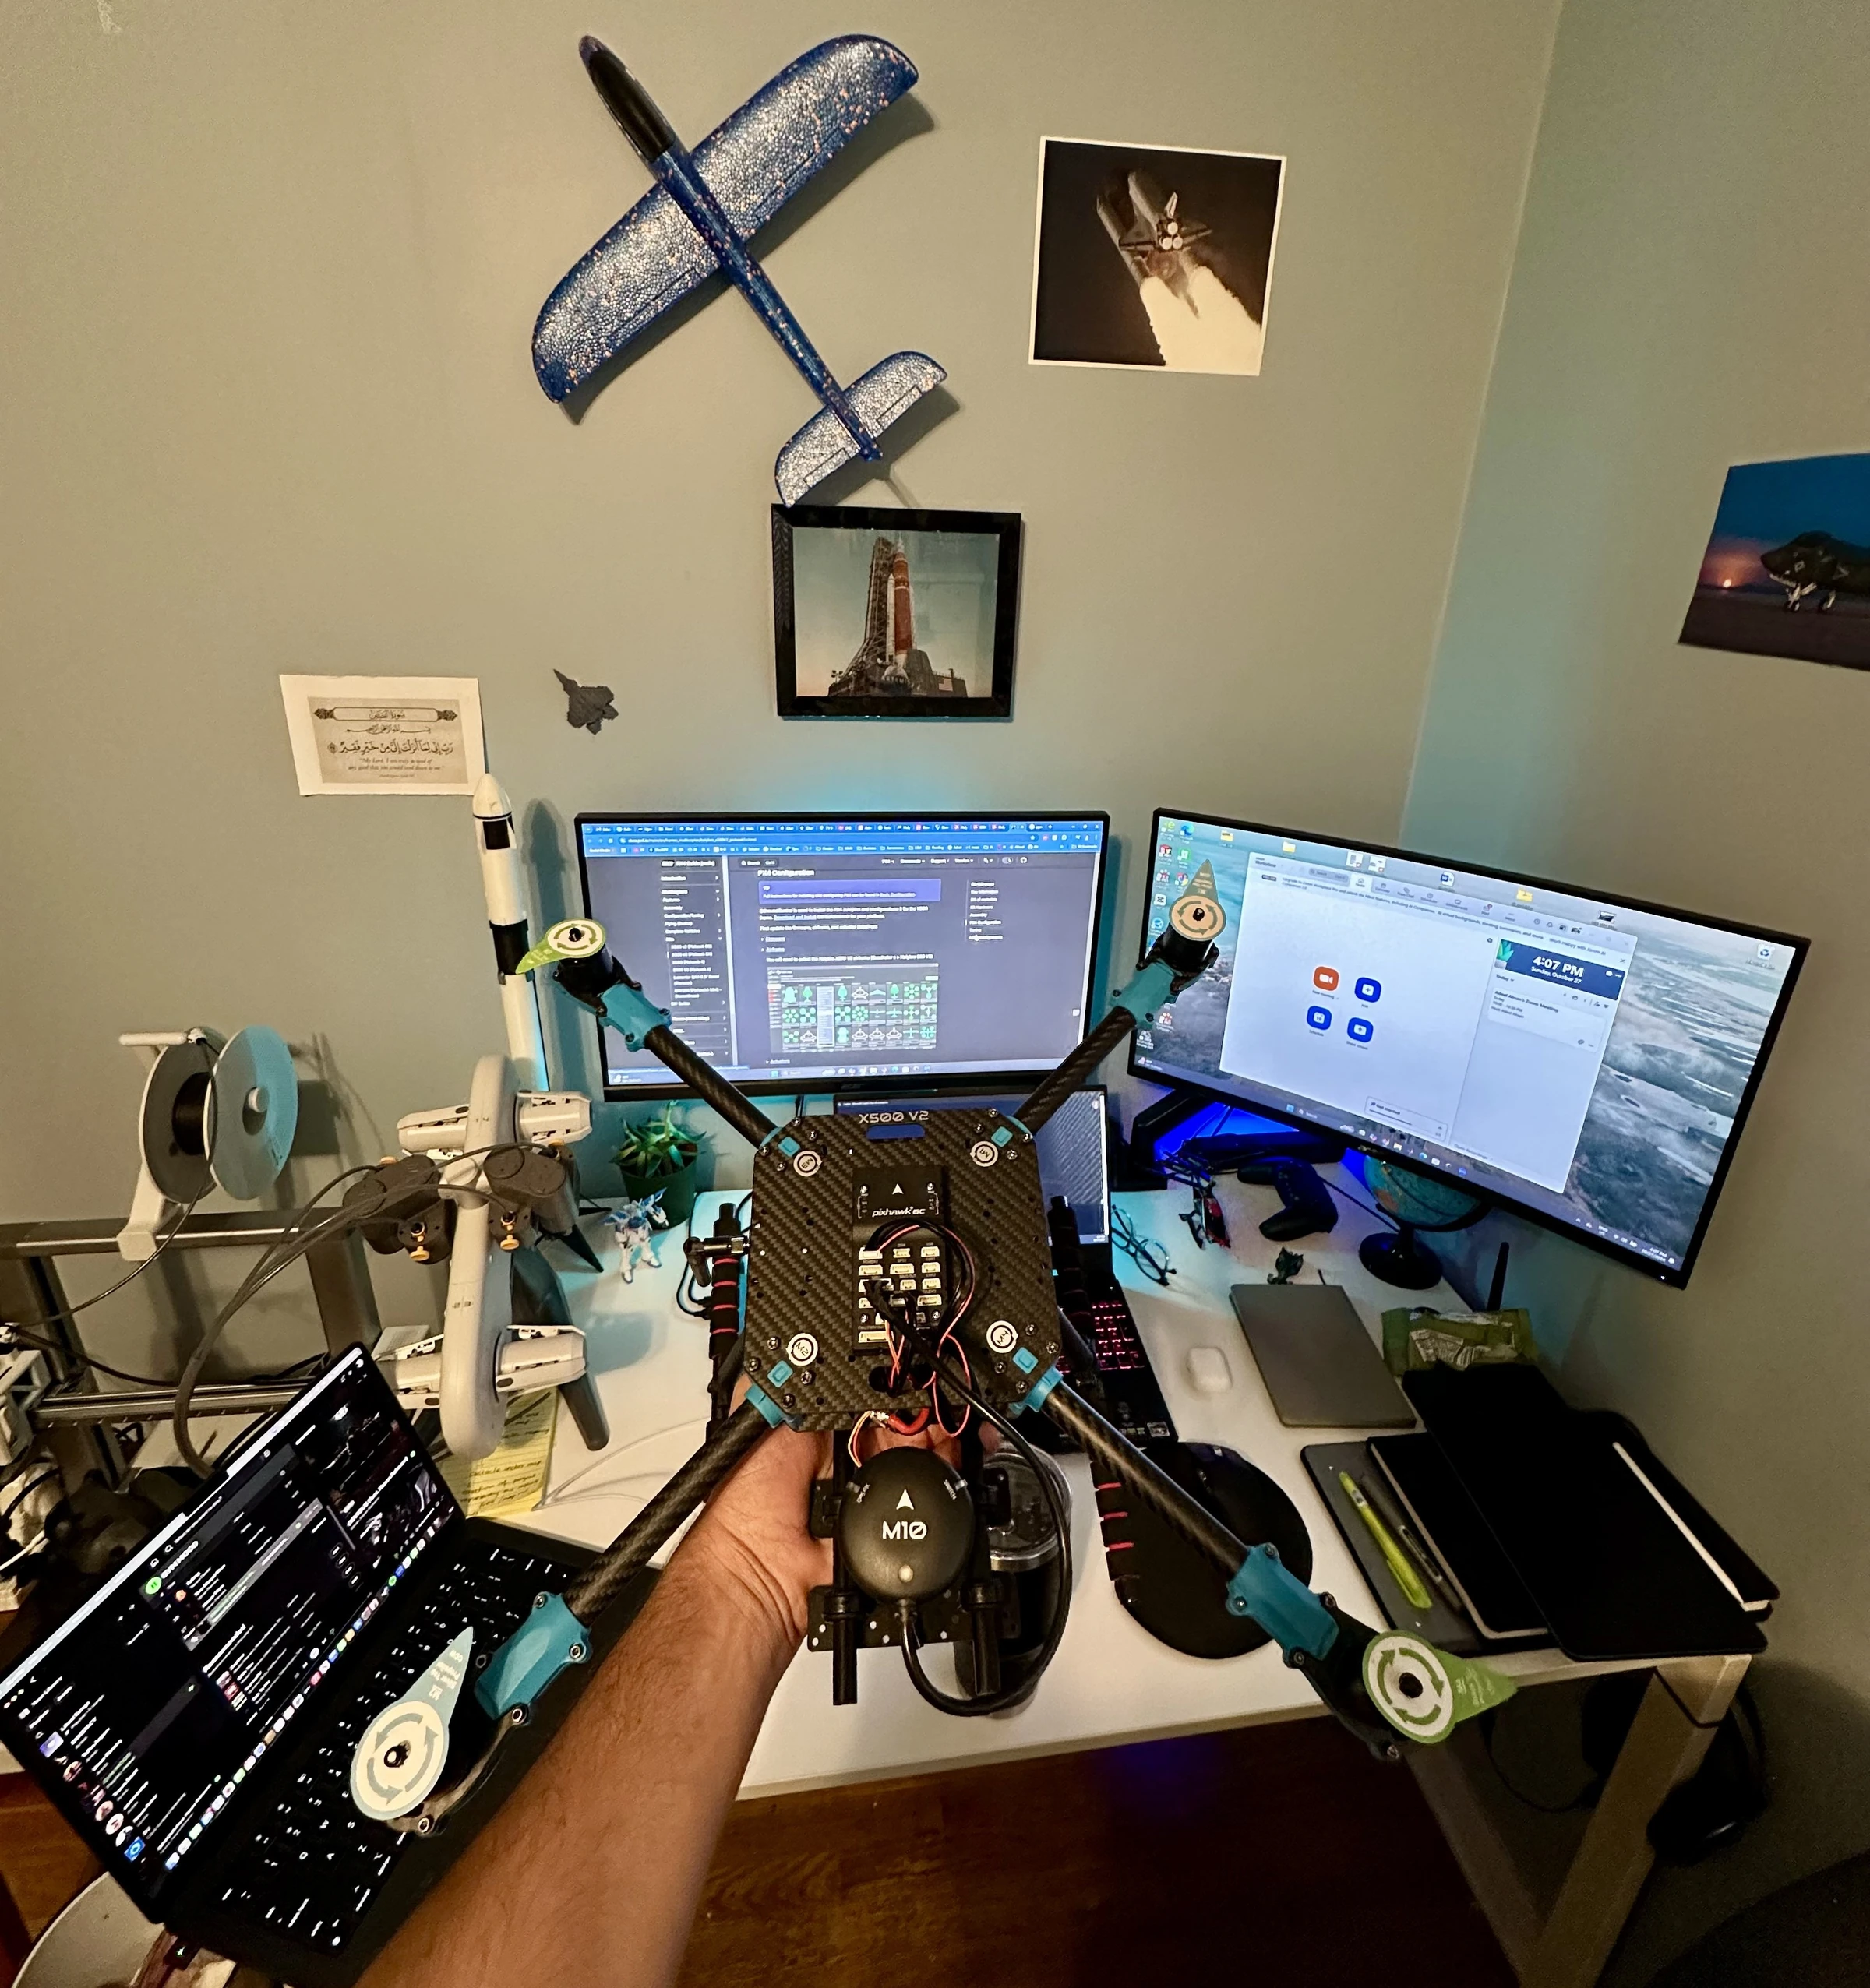
Current setup
Developing a Holybro X500 V2 test platform with a Pixhawk flight controller.