Optimization software
Multi-objective design engine
Three solver tracks; 36 saved benchmark rows across 12 cases.
Further work: an interactive Pareto-front comparison of the saved benchmark results.
A selection of my work in control systems, simulation, UAV planning and product development.
Interactive robot illustration. Use a pointer to explore; the casebook works on every device.
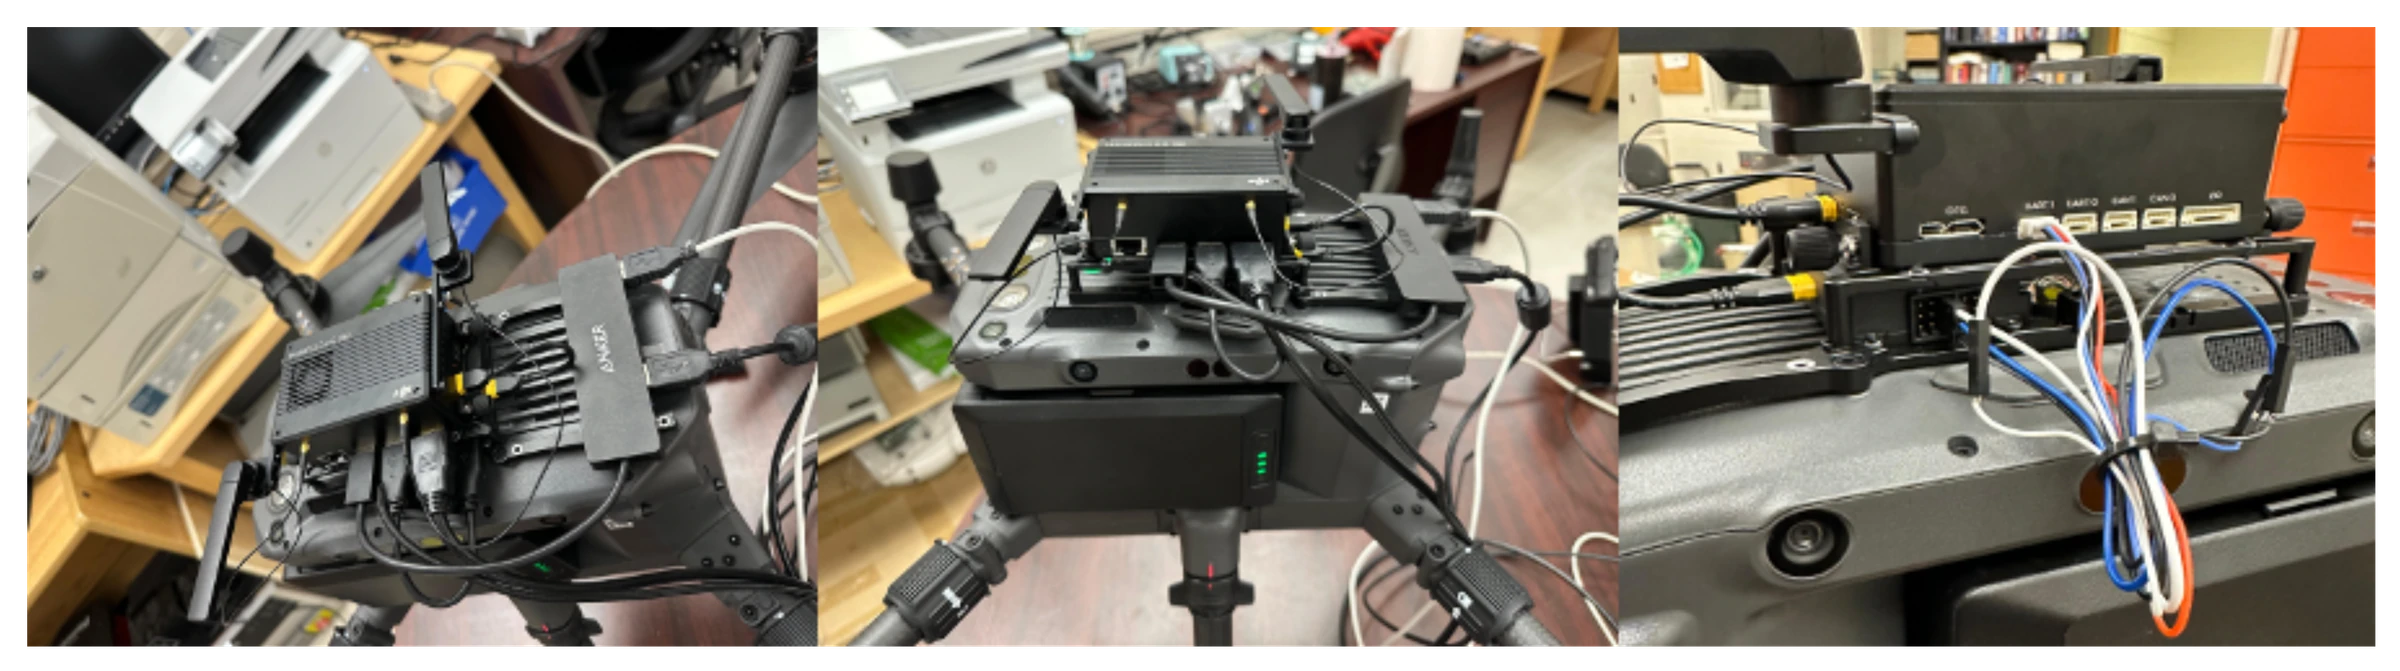
A hardware-in-the-loop setup connecting an aircraft model, controller and DJI M300 flight hardware.
Engineering case studies
Explore simulations, analysis tools and project figures. Each case explains the problem, my contribution, the method and the scope of the results.
14 case studies
 08Explore case study
Aerodynamics & structures
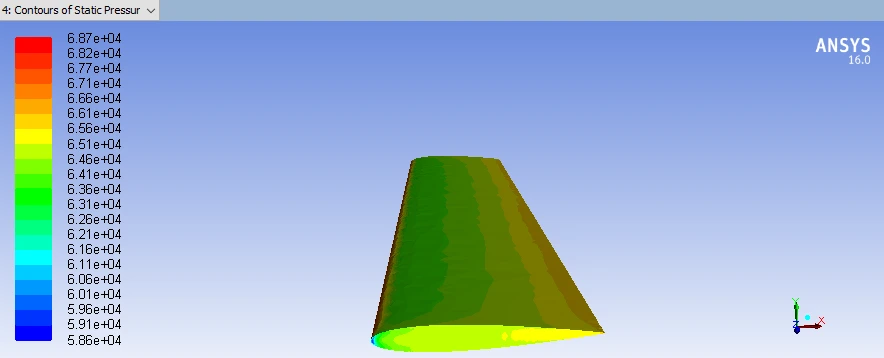
A NACA 0012 wing study that transfers CFD pressure loads into a structural model and compares stress, deflection and mass across nine structural variants.
CFD pressure loads · 9 structural variants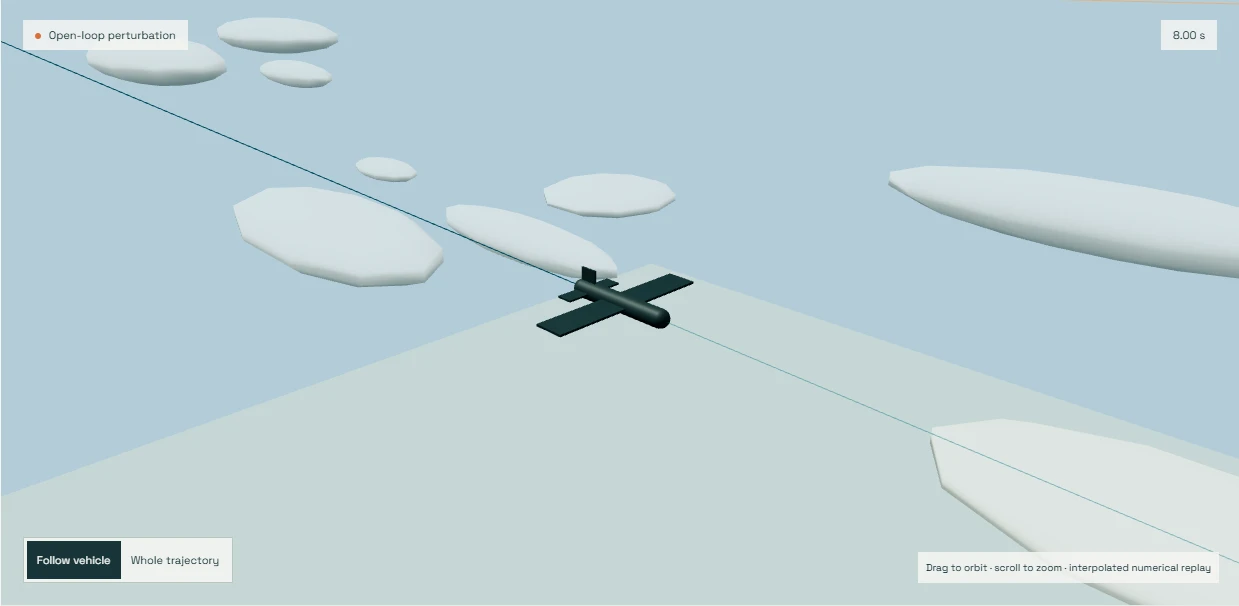 02Explore case study
Flight dynamics
Find a steady-flight operating point, derive a local linear model and compare its response with the nonlinear aircraft simulation.
MATLAB trim solution · matched linear / nonlinear responses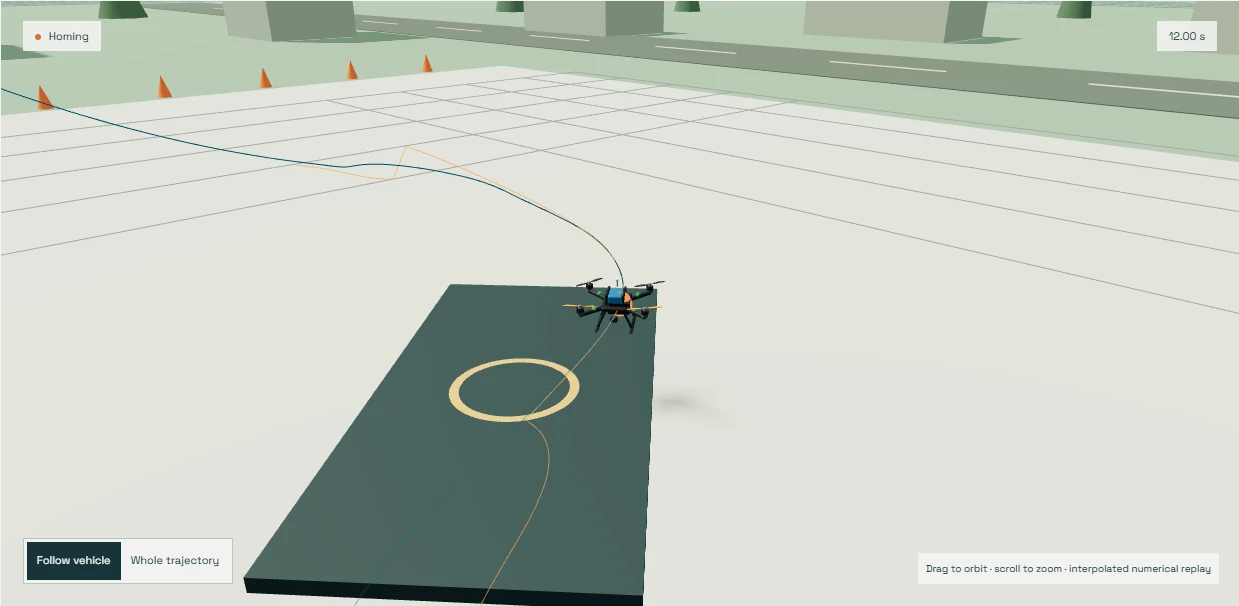 01Explore case study
Guidance & flight control
A nonlinear quadrotor simulation tracks a moving platform and transitions from approach to docking. Replay six scenarios alongside the state and control plots.
6 recorded MATLAB simulation scenarios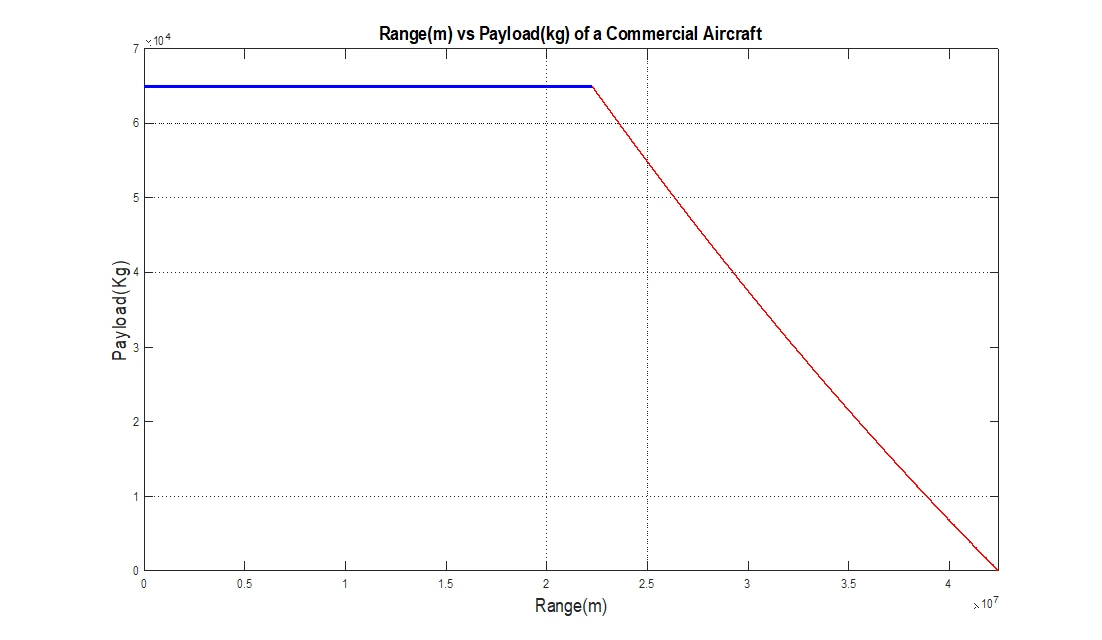 10Explore case study
Aircraft sizing
Explore how payload, range and fuel assumptions affect takeoff mass, alongside the mission and payload-range plots from a transport-aircraft sizing study.
Mission sizing · payload-range analysis · mass-budget explorer 04Explore case study
Machine learning & inspection
A computer-vision workflow for finding candidate defects in turbine imagery, with training metrics, validation figures and an image-by-image prediction explorer.
100 training epochs · saved validation and predictions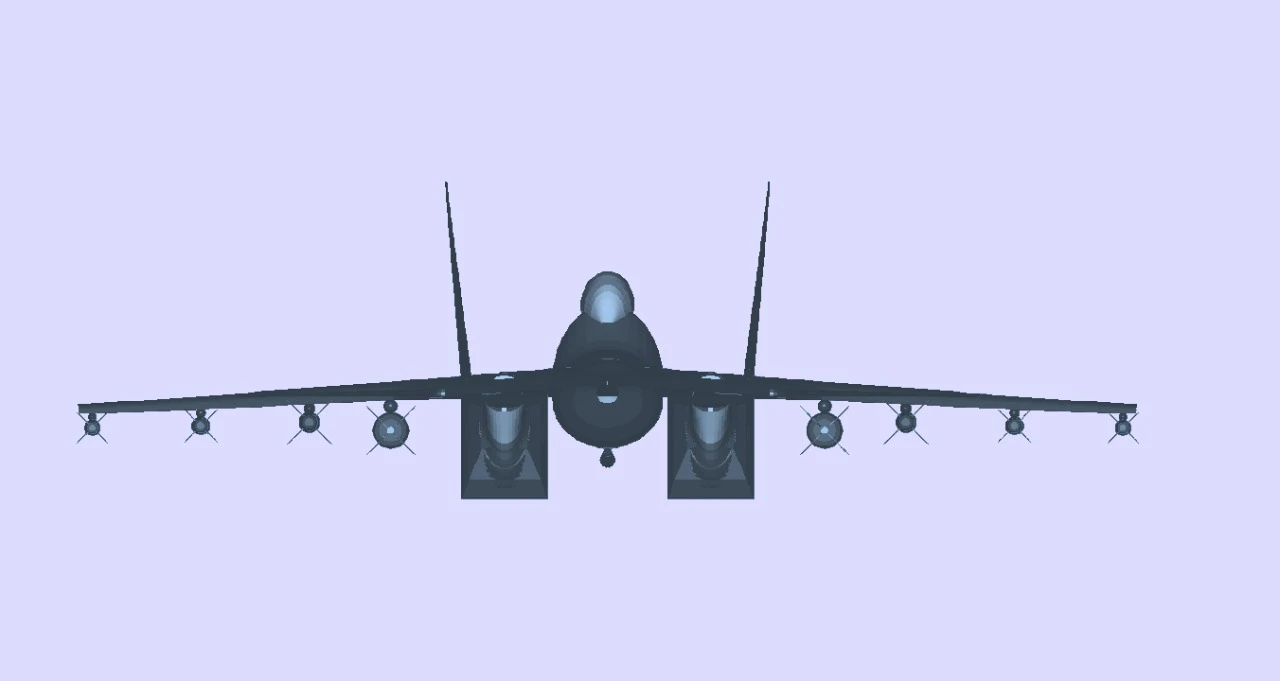 09Explore case study
Conceptual aircraft design
A joint conceptual aircraft-design project connecting requirements, mission sizing, CAD and Raymer Design Software (RDS) aerodynamic and propulsion studies.
Configuration development · CAD · design report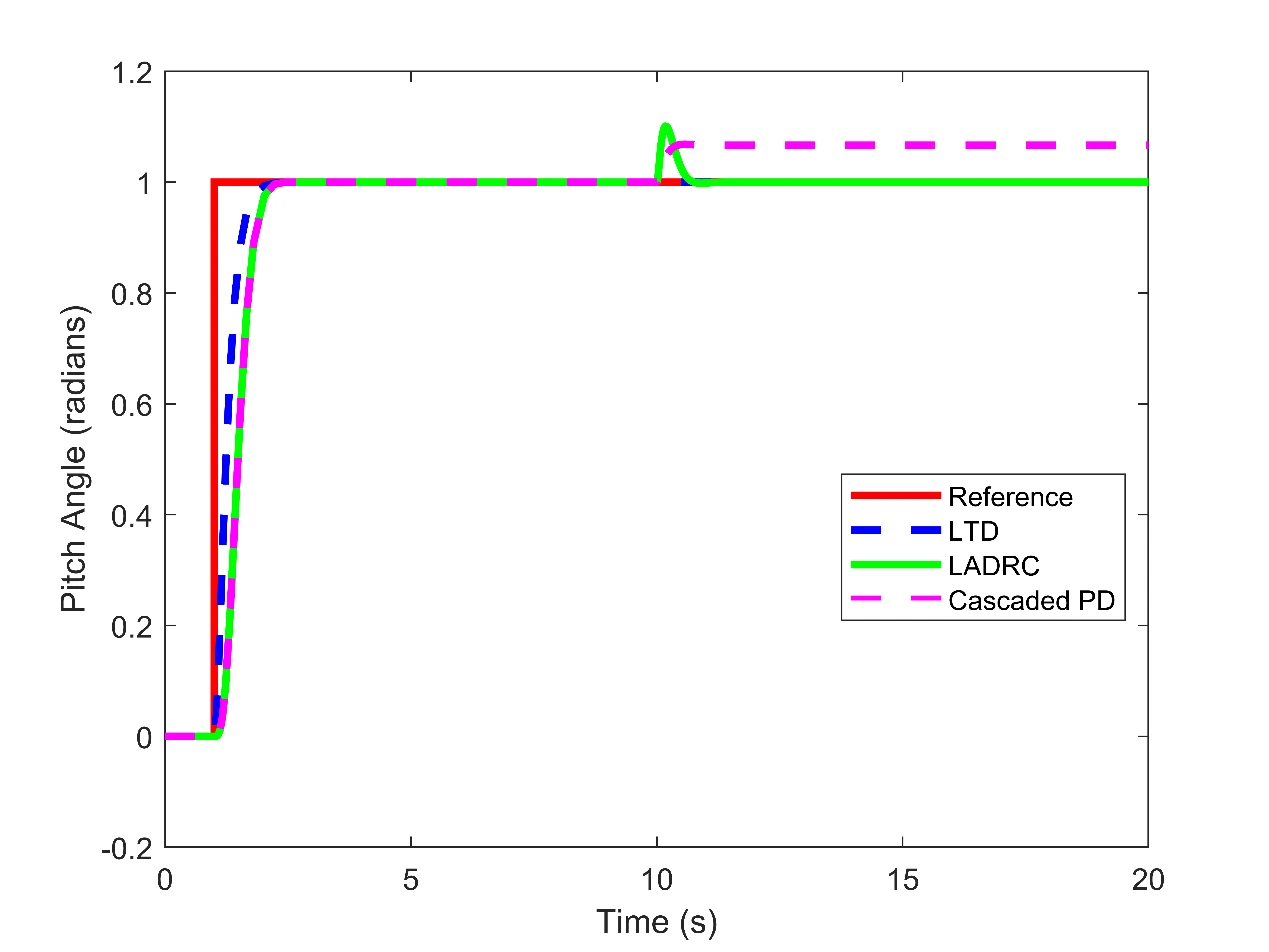 13Explore case study
Robust control
A nonlinear quadrotor simulation comparing cascaded PD and linear active disturbance rejection control, from vehicle modelling to discrete controller implementation.
Nonlinear simulation · disturbance tests · MATLAB S-functions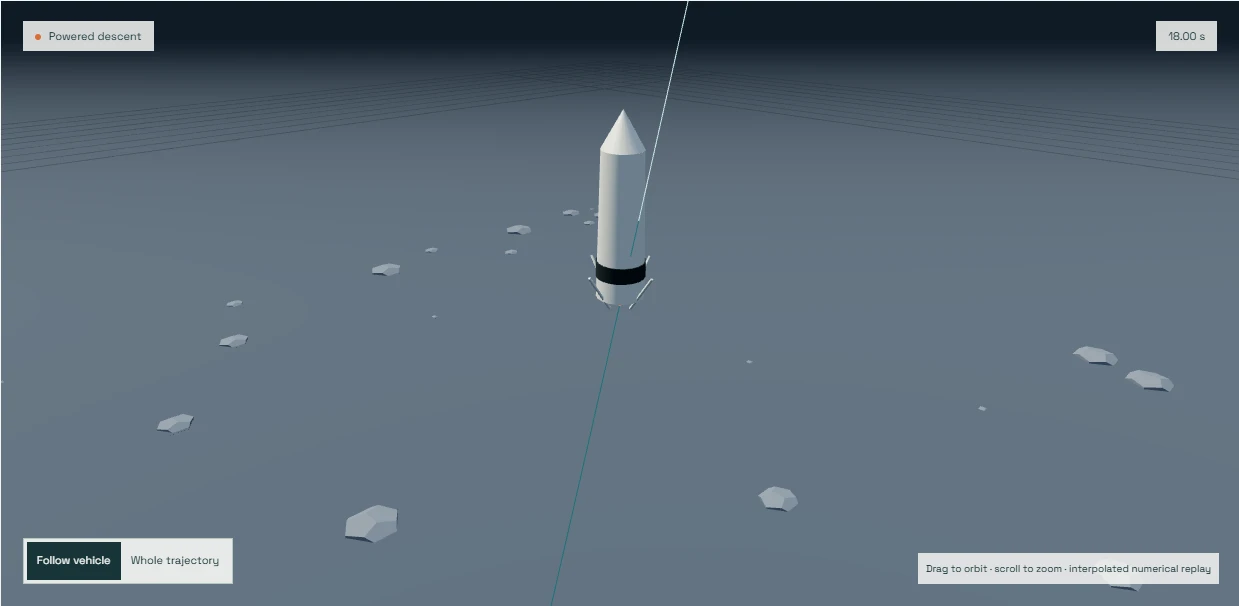 03Explore case study
Trajectory optimization
Optimize a lunar landing trajectory subject to thrust and tilt limits, then inspect altitude, velocity, thrust and estimated propellant use.
3-DOF trajectory optimization · Python / SciPy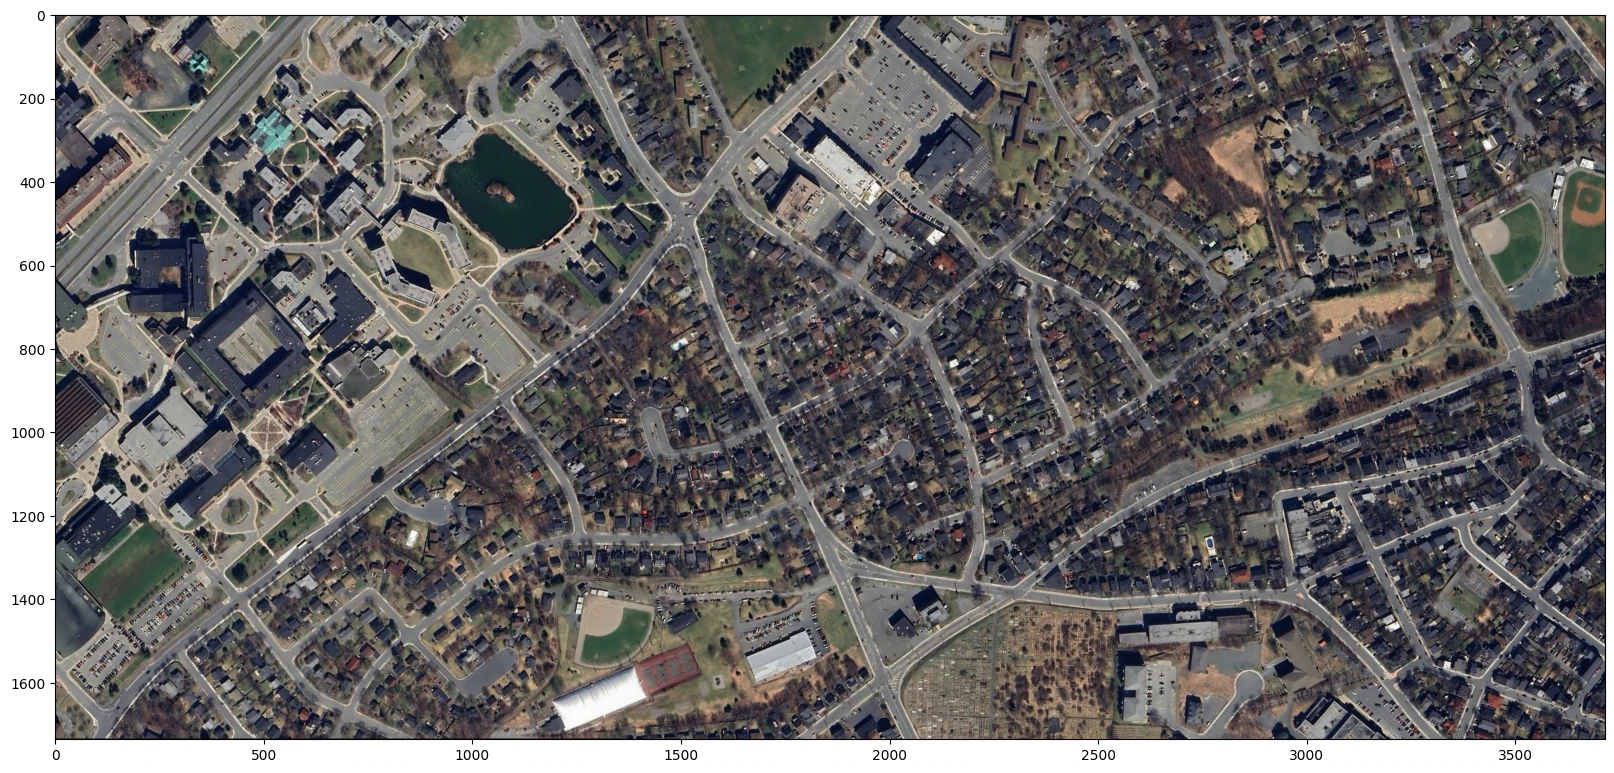 05Explore case study
Image processing & mapping
Align overlapping images into a larger composite using feature matching, geometric registration, warping and blending.
Original overlapping images · saved mosaic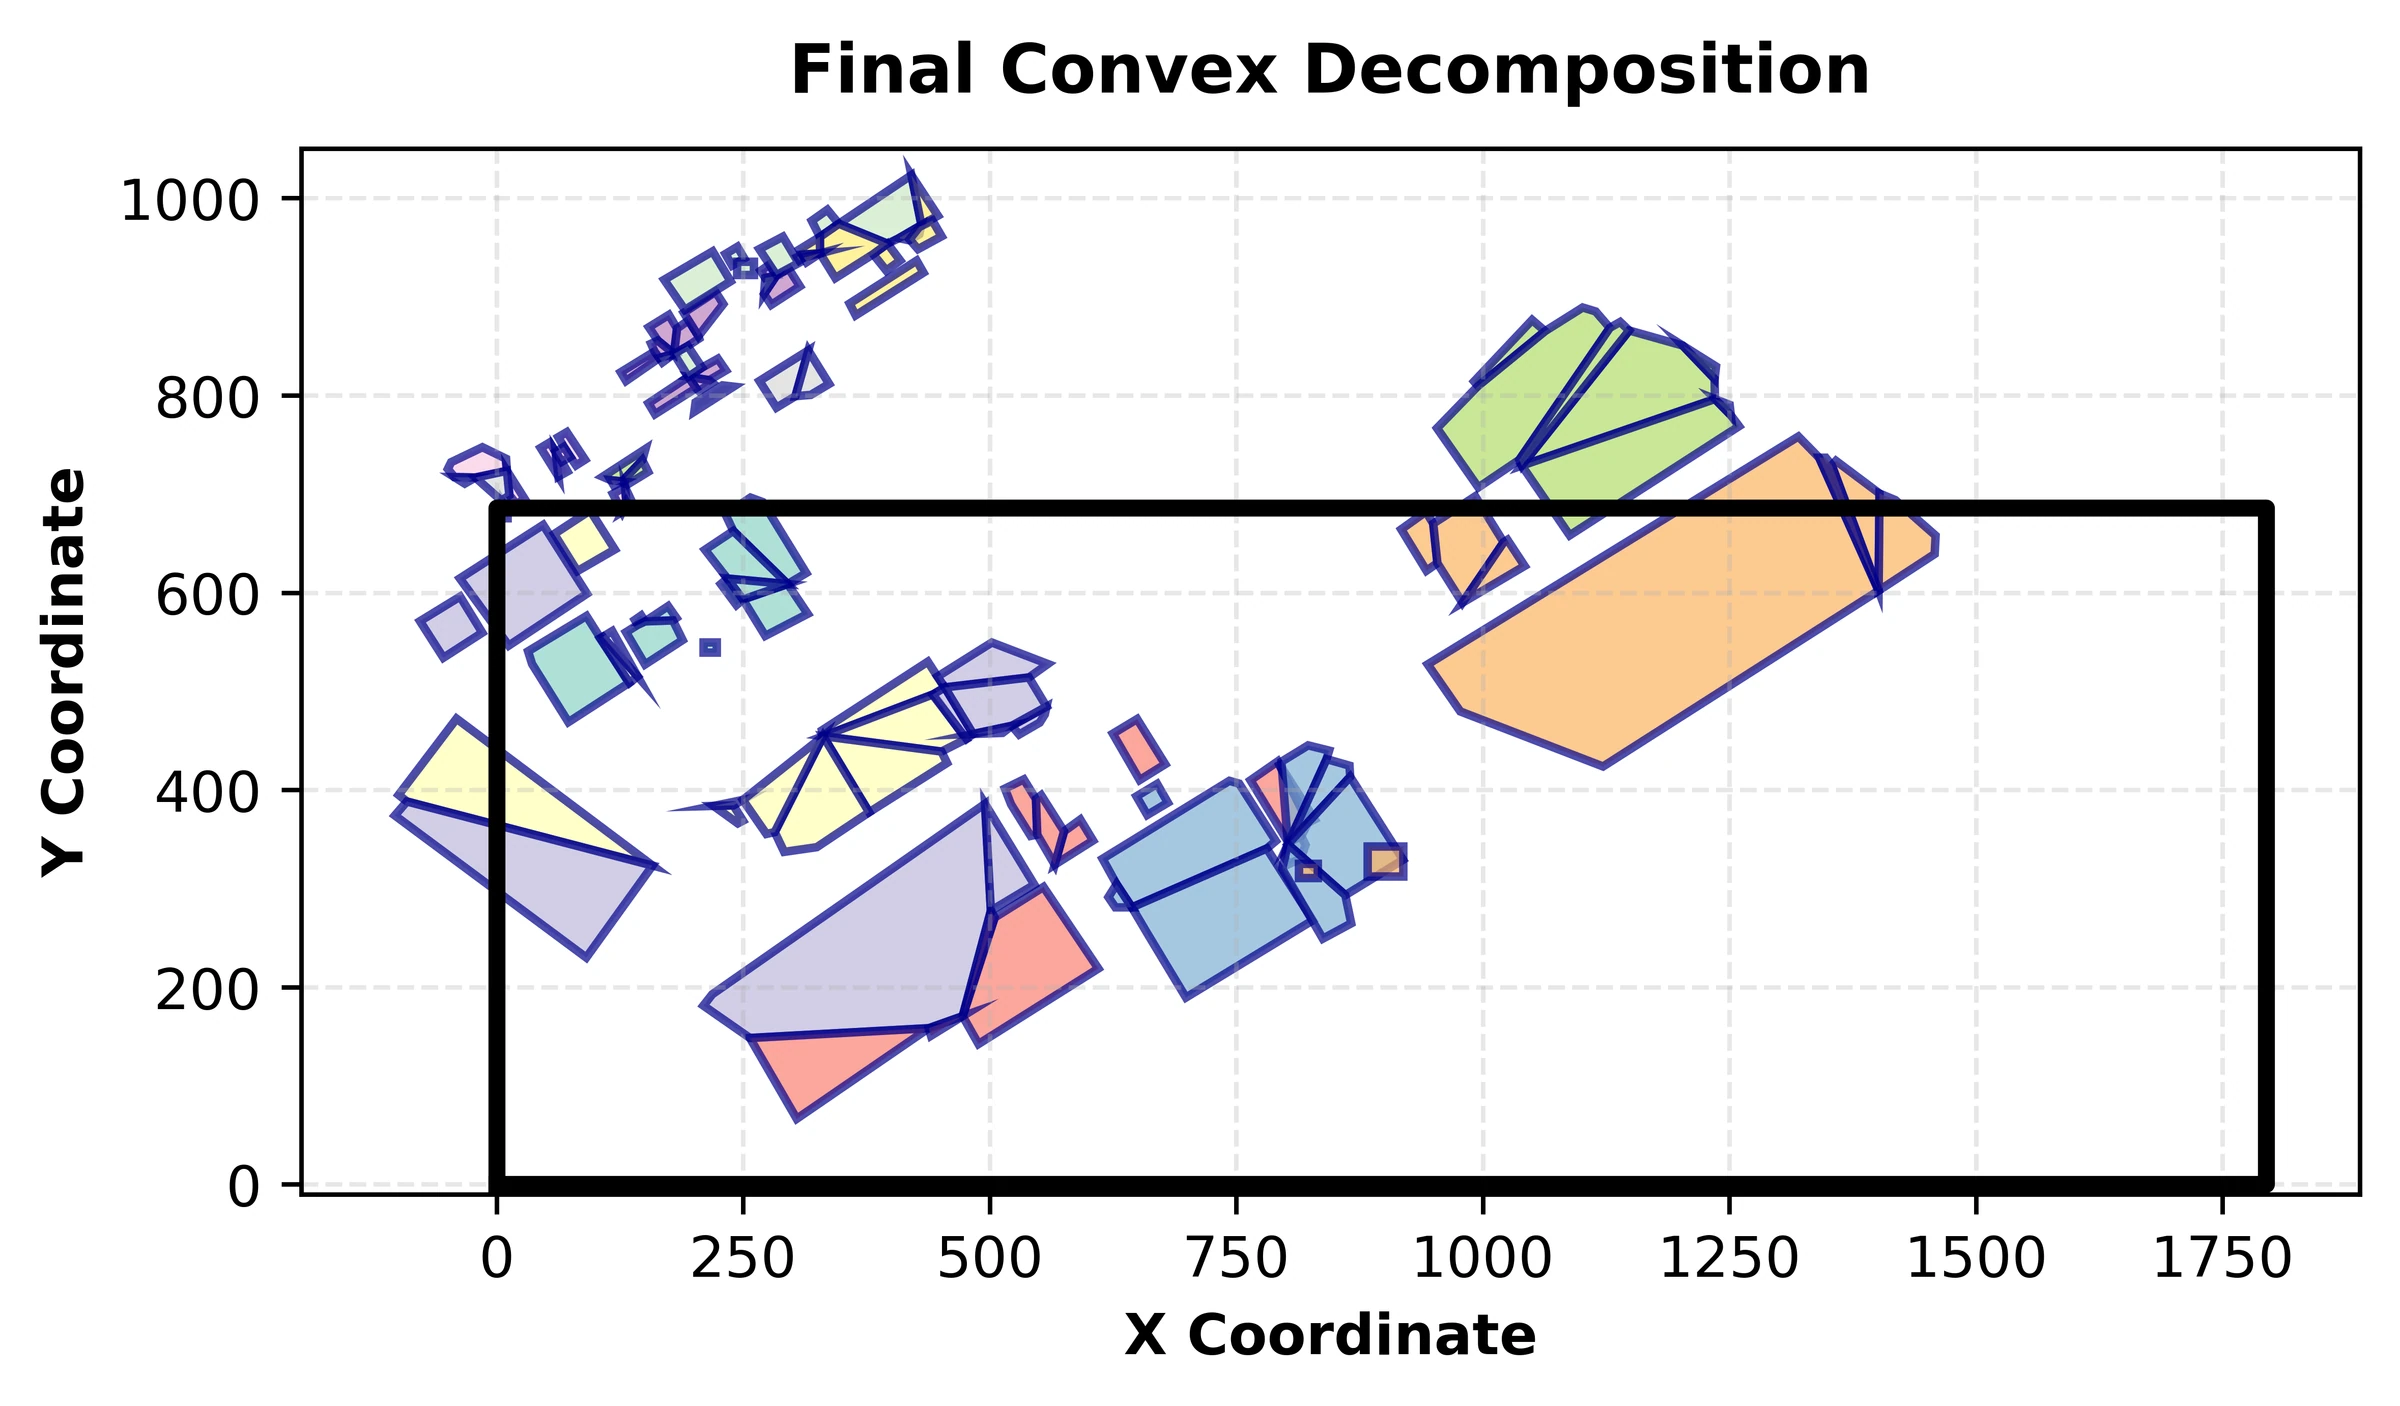 06Explore case study
Planning & numerical methods
Turn an obstacle-free route into a smooth trajectory using convex corridors and Bézier curves, with explicit limits on motion.
Research outputs · interactive planner07Explore case studyRobotics integration
Connect ROS, DJI flight hardware and a simulated aircraft response to exercise trajectory-control software before flight testing.
Hardware setup · research footage & logs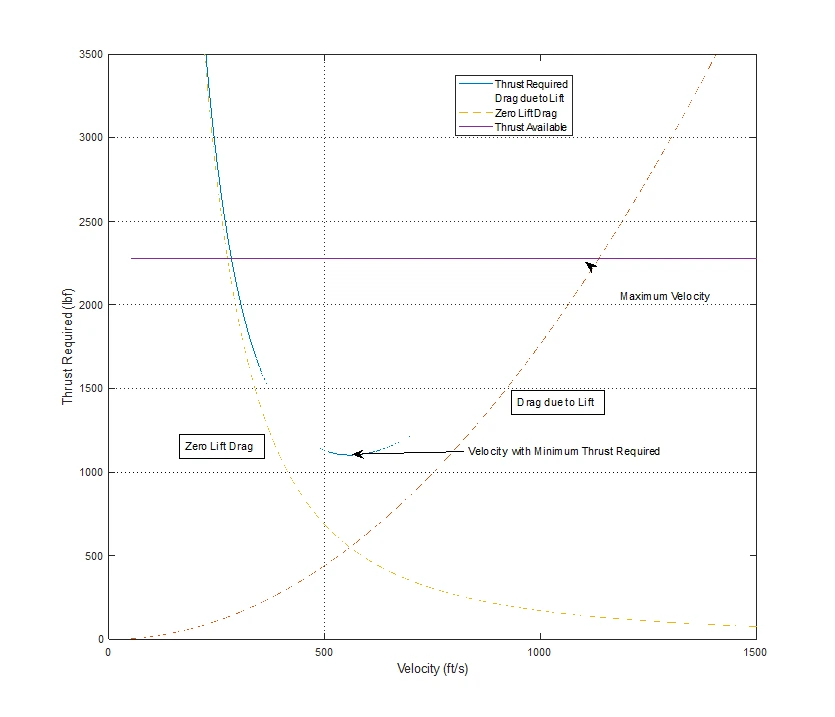 11Explore case study
Civil aircraft performance
An aircraft-performance calculation study, with original report plots and an interactive example of drag, thrust margin and ideal climb potential.
Original report plots · interactive drag / power model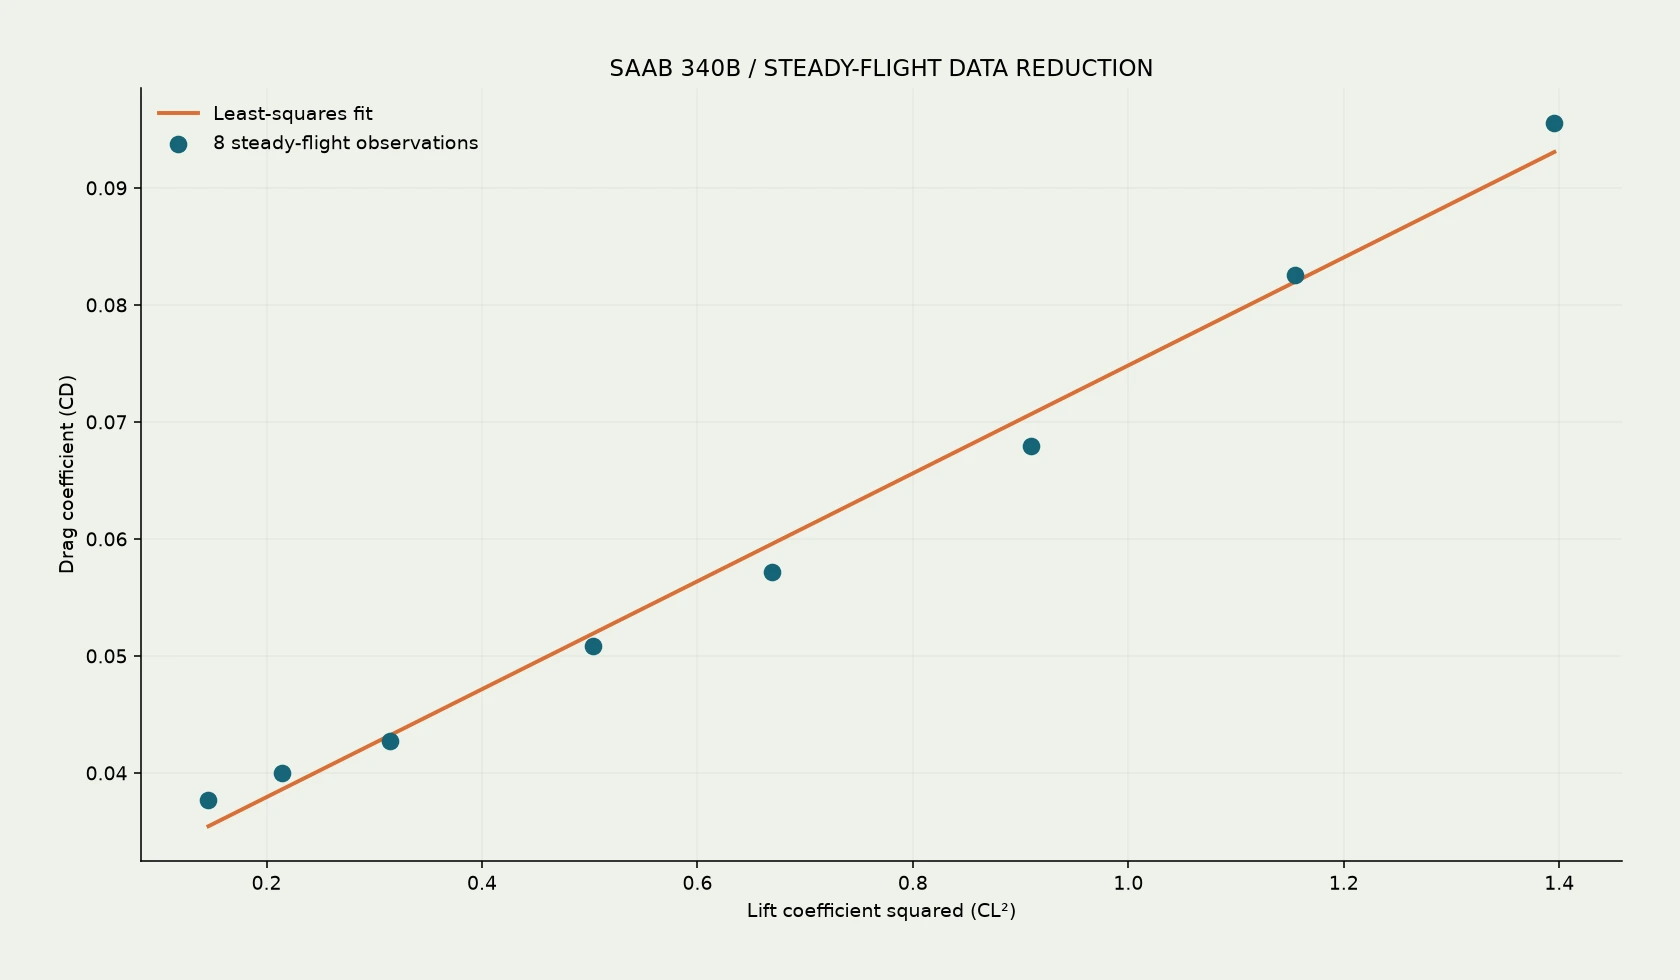 12Explore case study
Flight-data reduction
Estimate lift and drag coefficients from eight steady-flight observations, fit a drag polar and examine the residual at each operating point.
8 steady-flight observations · coefficient reduction · least-squares fit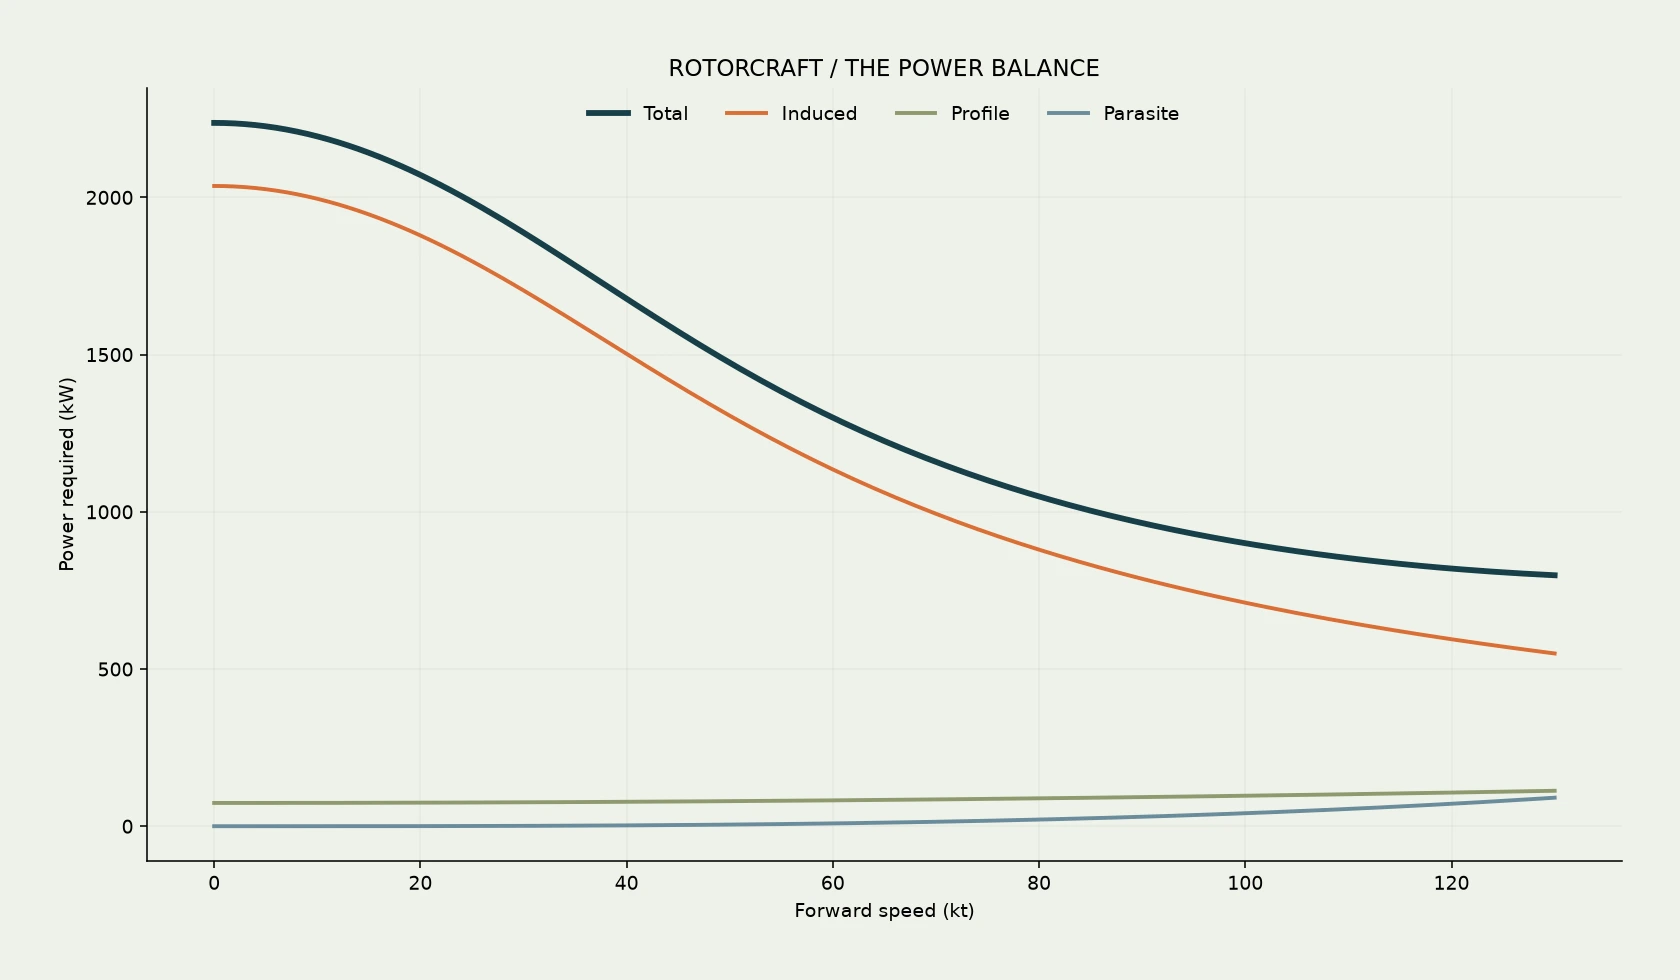 14Explore case study
Rotorcraft aerodynamics
Break helicopter power demand into induced, profile, parasite and tail-rotor contributions, then explore the ideal climb margin over airspeed.
Power breakdown · airspeed sweep · ideal climb analysisProject work / 01–16
Additional control studies, simulations and software projects, with supporting figures and links.
A ROS and DJI OSDK setup for testing trajectory planning and control with real flight hardware and a simulated aircraft response.
Original setup photographs and system diagram. Hardware-in-the-loop evidence is distinct from free-flight testing.
Explore the hardware-in-the-loop casePlanning smooth trajectories around obstacles using convex corridors, differential flatness and Bézier curves.
Saved planning outputs, with the product film and interactive planner as companion material.
Explore the planning methodA YOLOv8 workflow for detecting candidate defects in turbine imagery, with saved validation results and predictions for visual review.
Confusion matrix, precision–recall curve, and paired validation labels/predictions from the same saved 100-epoch training run.
Inspect predictions and training history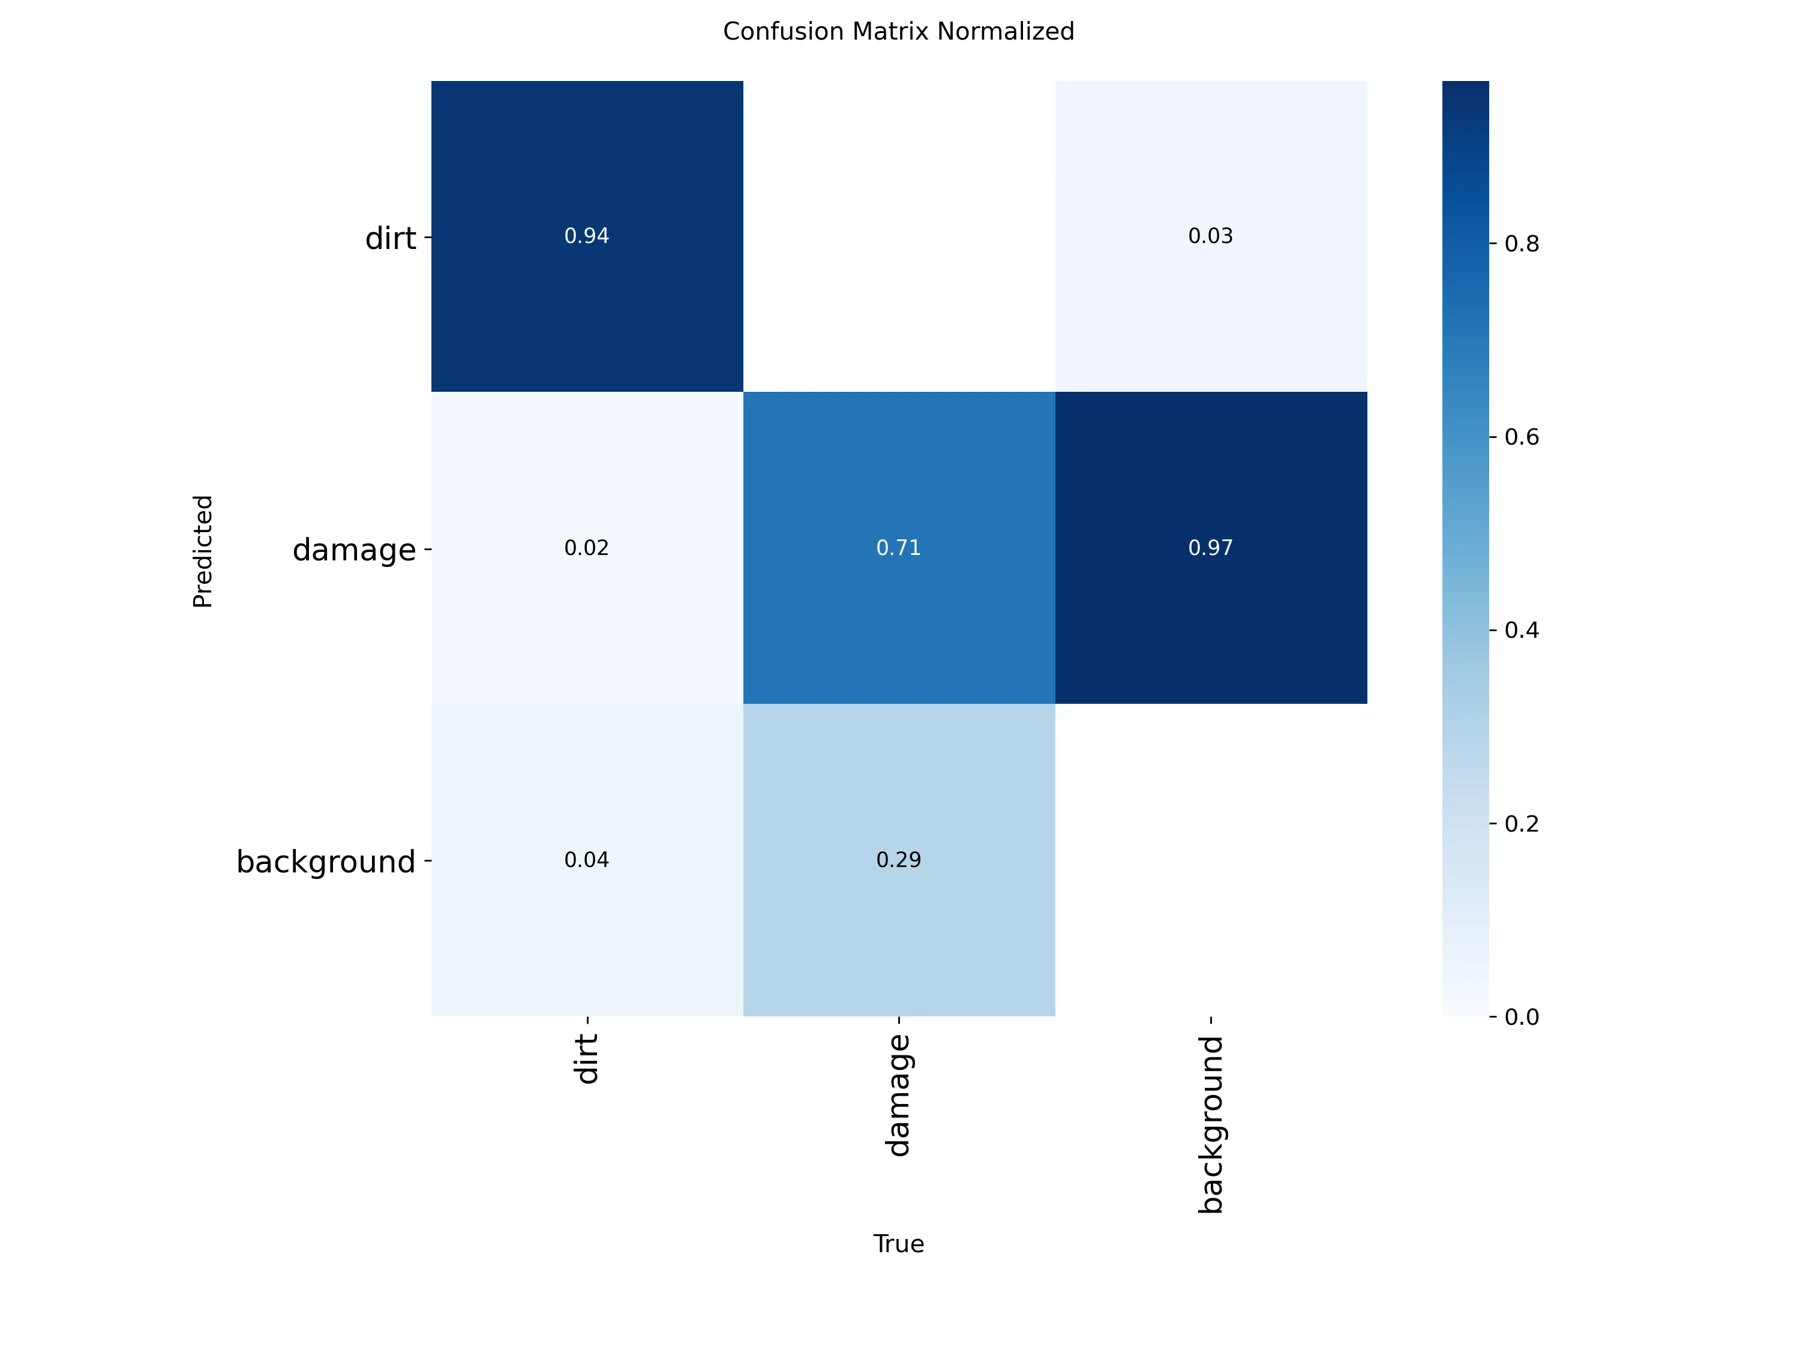
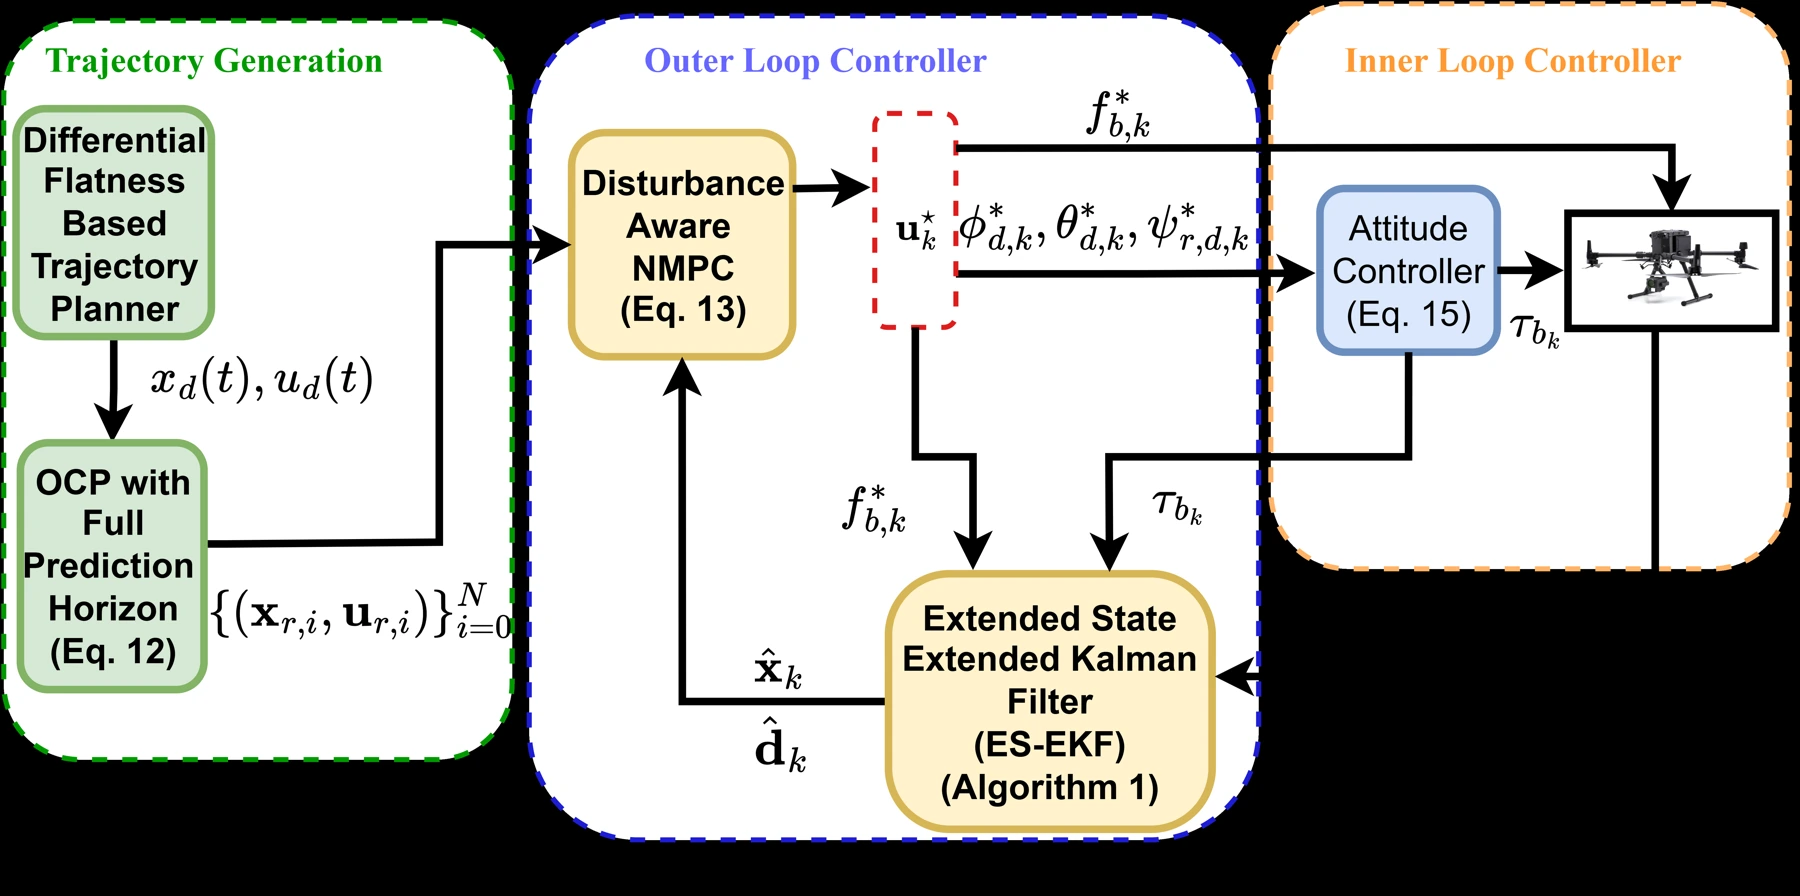
Estimating external disturbances and using nonlinear model predictive control to compensate for them.
Simulation figures show the control architecture, applied disturbances, disturbance estimates and trajectory tracking from the study.
An app for exploring customer problems, reviewing research sources and organizing customer discovery. Watch the product film or request access.
The product film above shows the app workflow. The app page describes the product and access options.
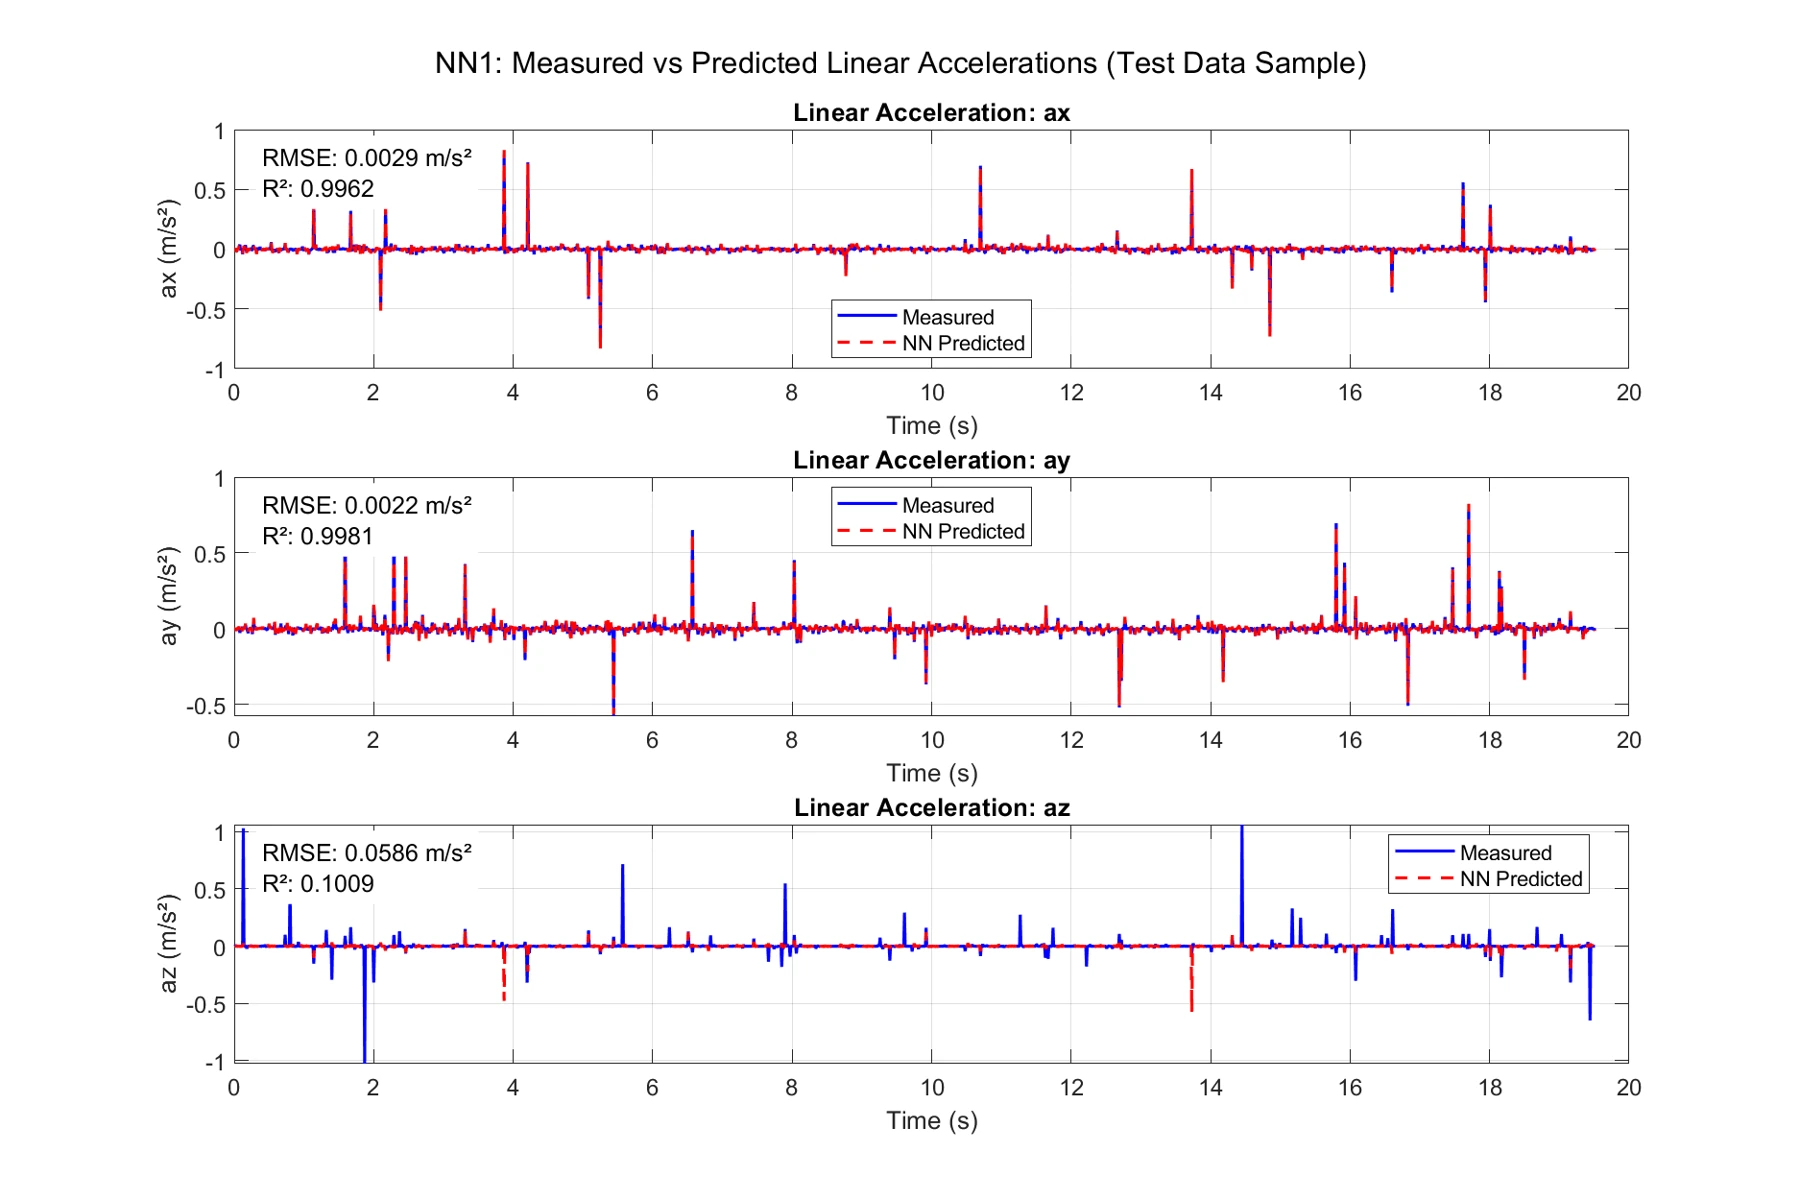
View the Reddiate app pageA MATLAB experiment using separate neural networks for quadrotor translational and rotational dynamics, with saved prediction comparisons.
Separate neural networks model translational and rotational quadrotor dynamics. Prediction and correlation plots show how each acceleration channel is represented, including lower accuracy in the vertical channel.
Aligning and blending overlapping satellite images into a larger mosaic using Python and OpenCV.
A source image and its saved mosaic. The detailed case includes the overlap, registration and blending explanation.
Explore the image-mosaic workflow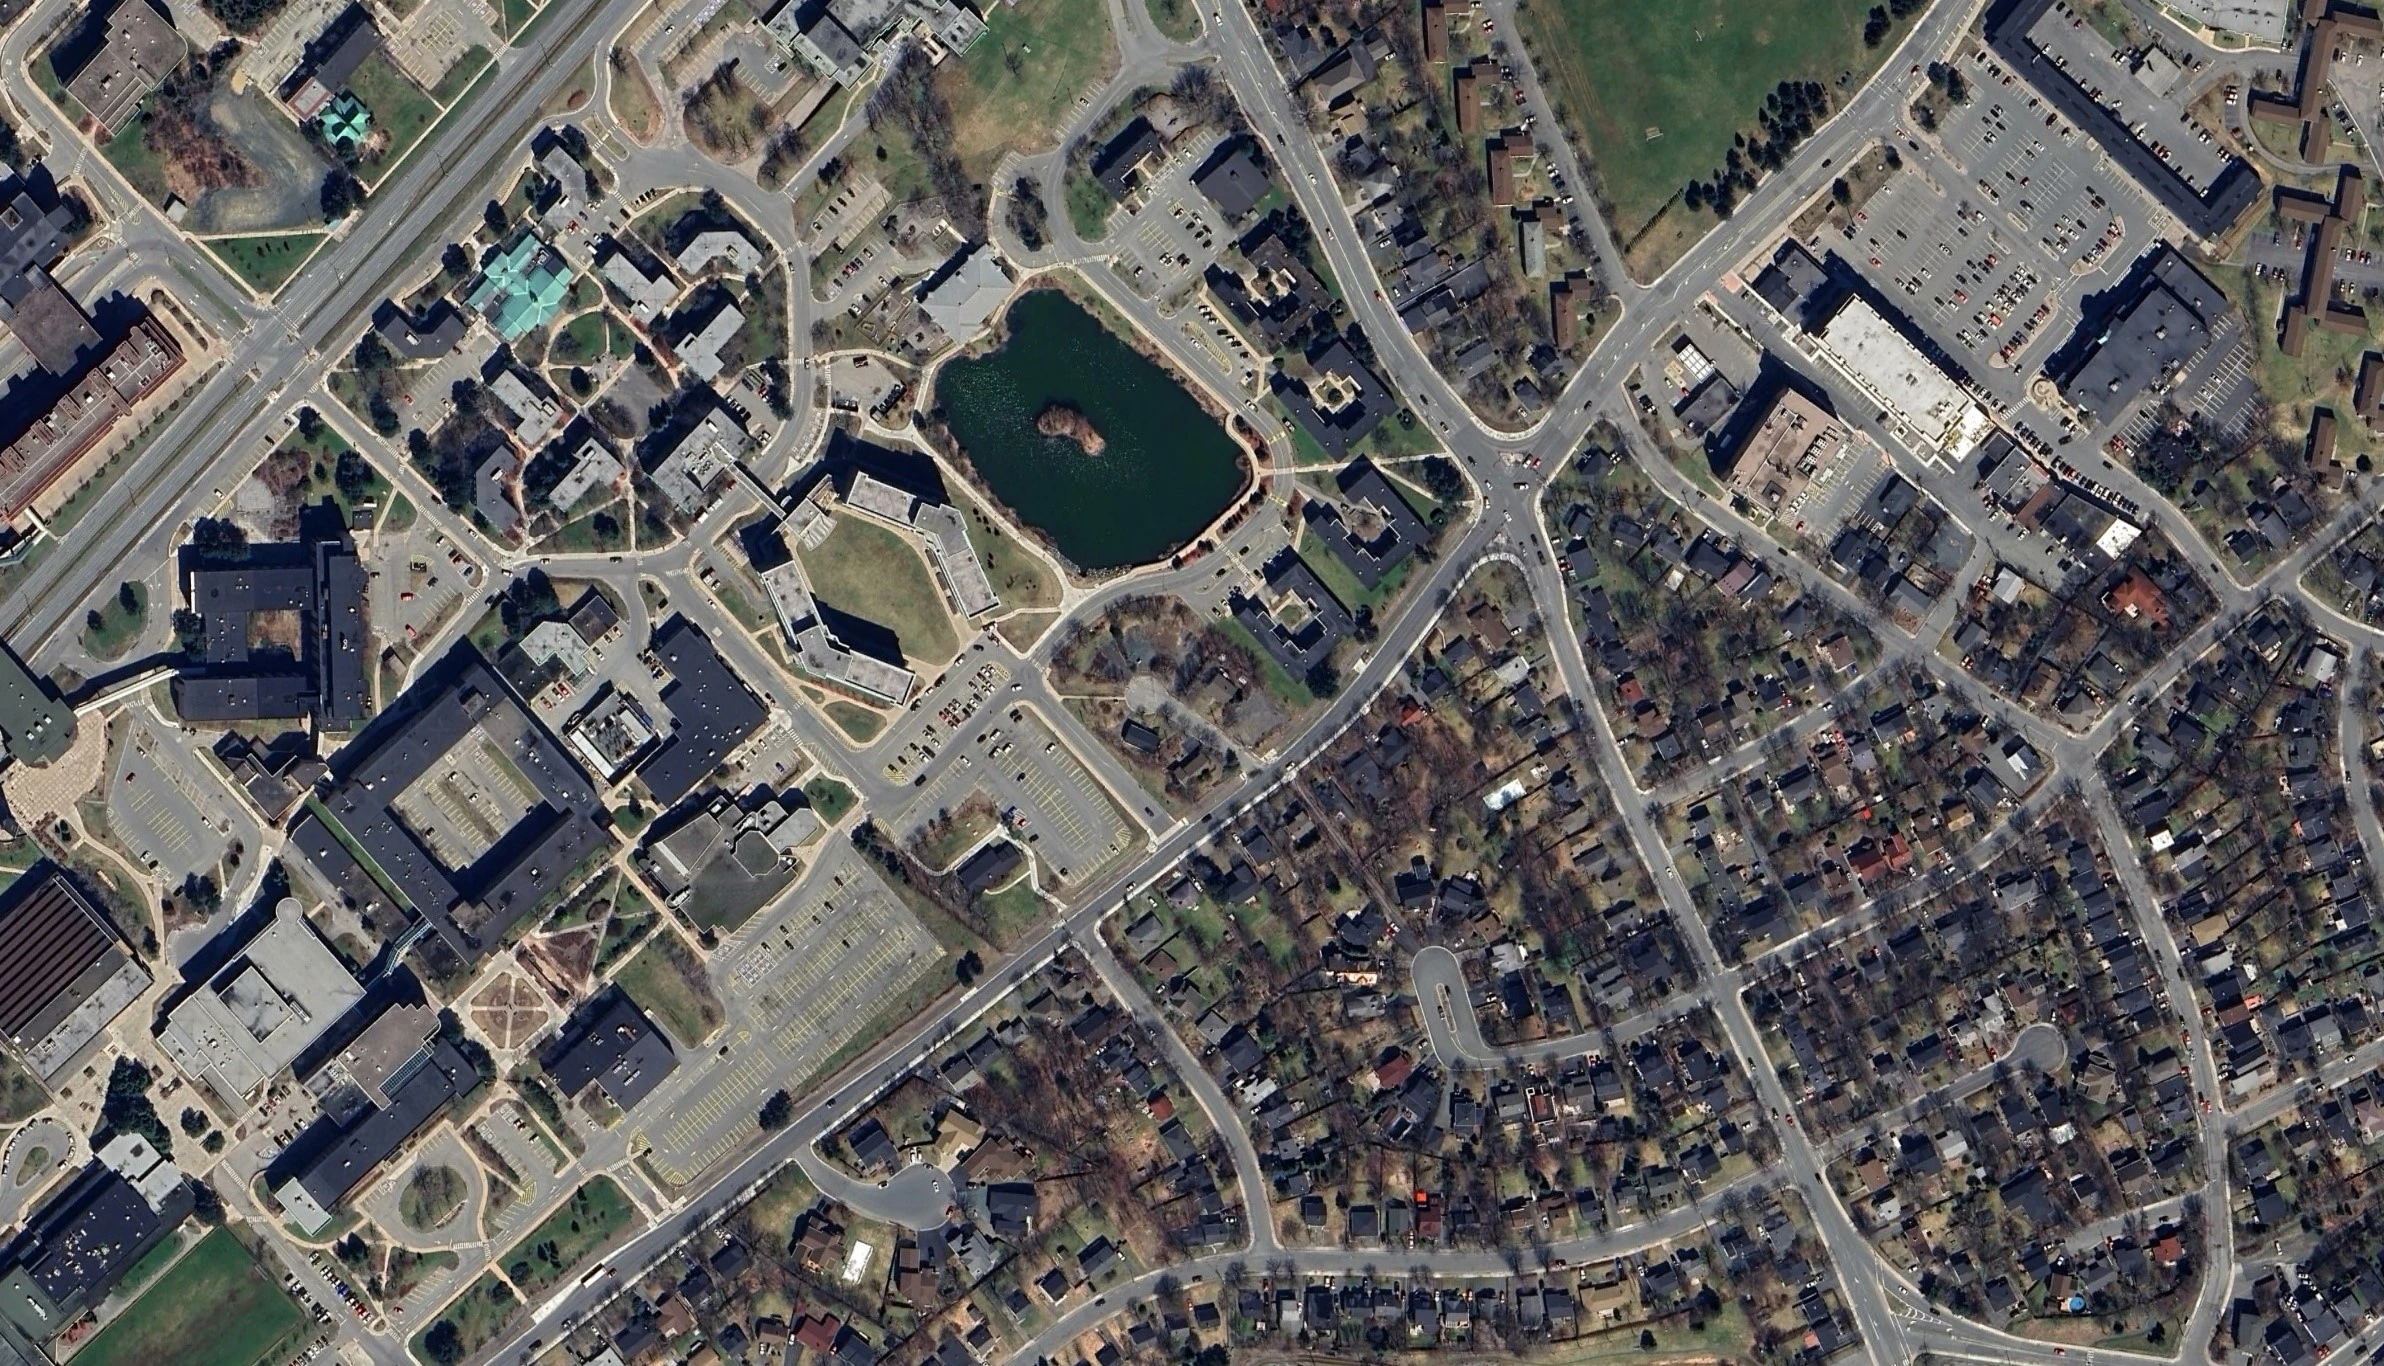
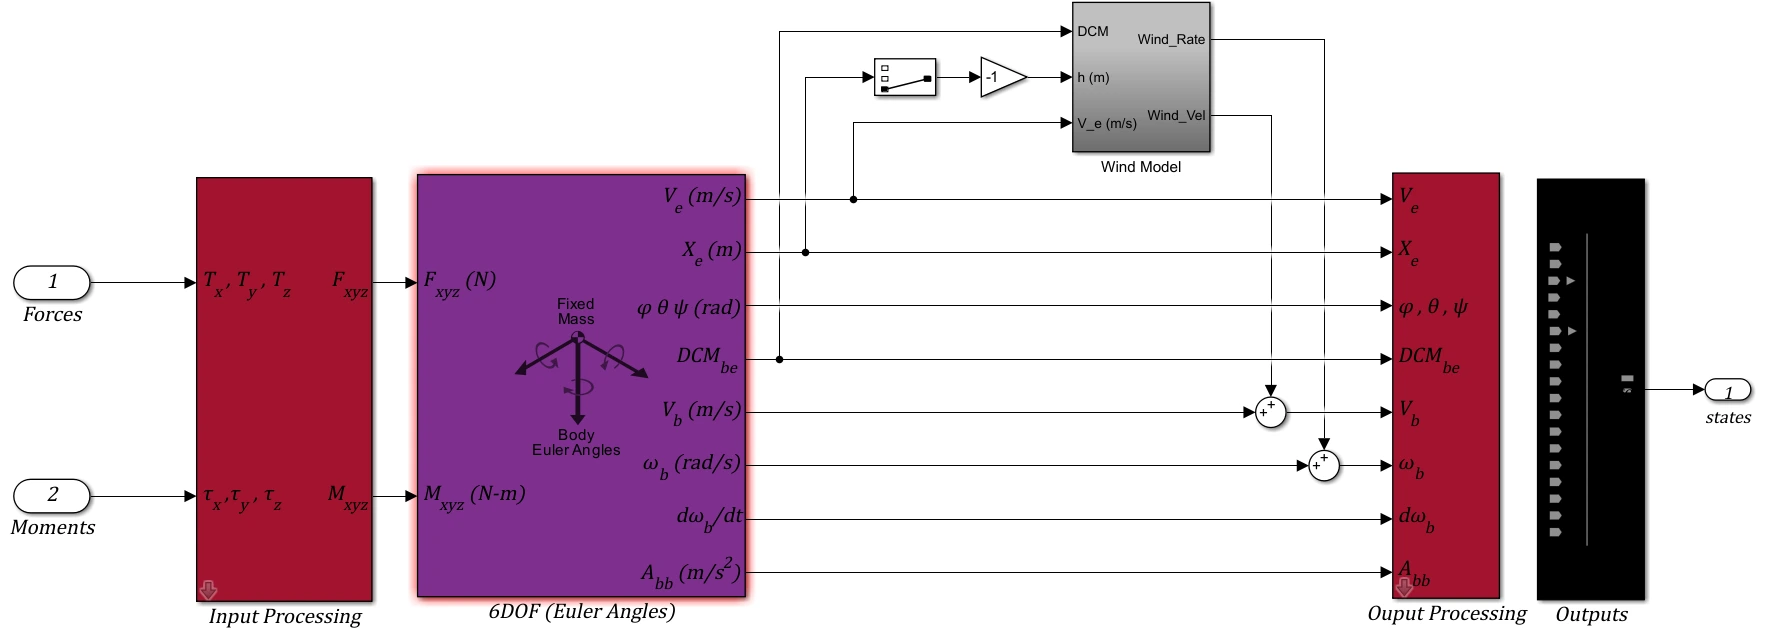
A nonlinear 6-DOF simulation with proportional navigation and a three-loop autopilot.
A nonlinear 6-DOF UAV model incorporating actuators and sensors.
Dynamics, actuator and sensor diagrams explain how the tilt-rotor simulation is assembled.
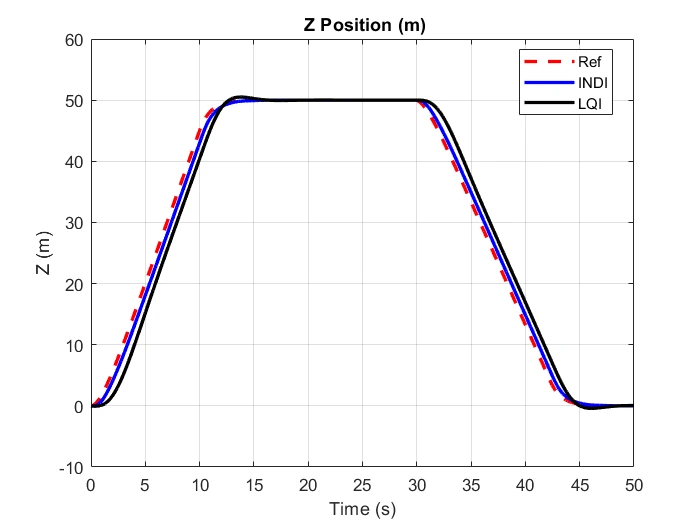
Incremental nonlinear dynamic inversion for simulated attitude and altitude control.
A nominal altitude-response comparison and implementation diagrams from the shared INDI / tilt-rotor model.
A nonlinear aircraft model with stability augmentation and autopilot modes.
Model, response and control-structure figures from the original fixed-wing control report. The newer trim study is a separate related model.
Related trim and linearization study
A simulation study comparing active disturbance rejection control with other quadrotor controllers under the study’s test conditions.
Control architecture, nominal response and model-uncertainty results from the comparative quadrotor-control study.
Related PD / LADRC control study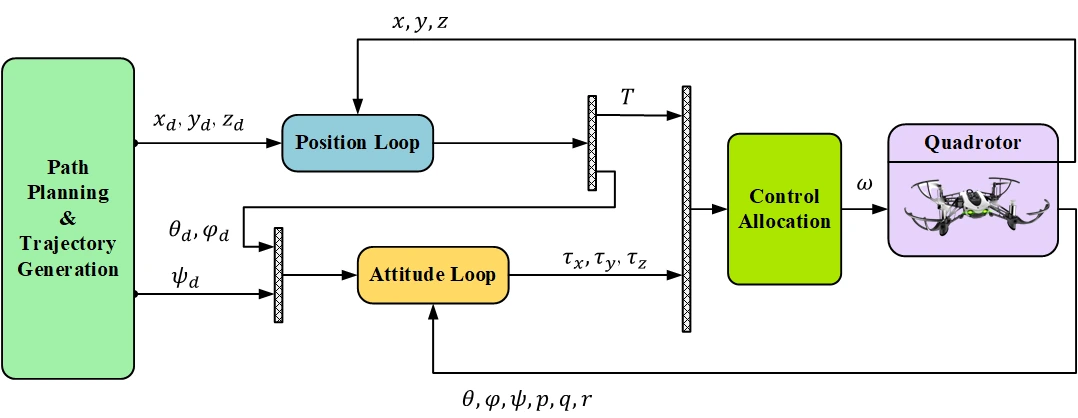
FireBolt, a joint conceptual-design project with Mariyam Abid, covering requirements, aircraft sizing, configuration development and CAD.
CAD and design-report figures from the joint project by Muhammad Adeel Ahsan and Mariyam Abid.
Explore the aircraft-design case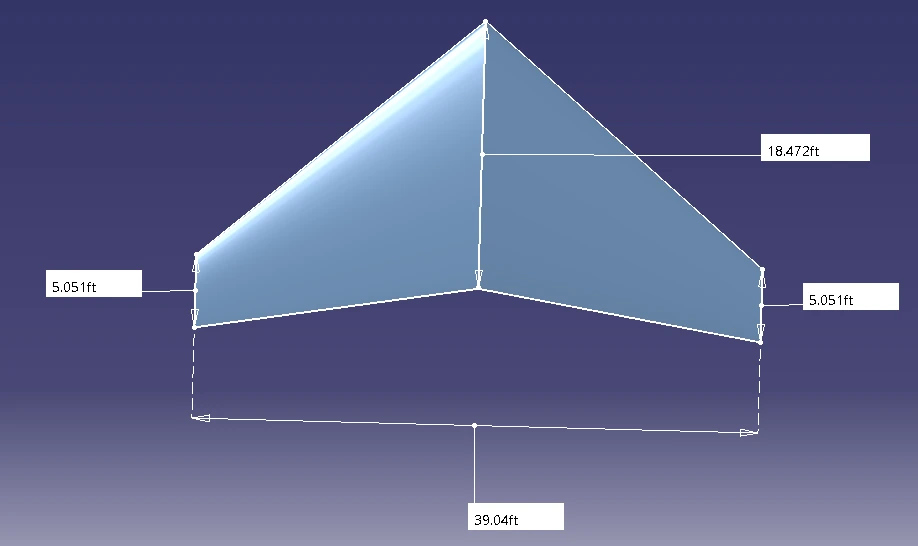
A NACA 0012 finite-wing study connecting CFD pressure fields to static structural response and comparing nine structural variants.
Original wing-flow and structural-analysis figures, with the archived numerical comparisons in the linked case.
Inspect the wing study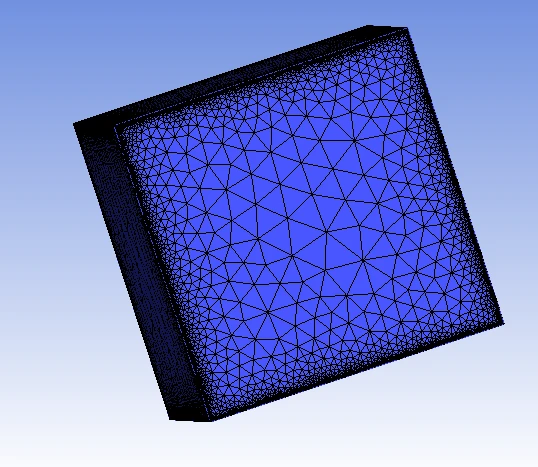
Longitudinal and lateral autopilot design for an aircraft simulation.
Aircraft-performance analysis using analytical methods for flight mechanics.
Control, in practice
Explore how controller gains affect a model’s response in the PID tuner.
Open the PID tunerCommand → response → feedback
Illustrative step response
Currently building at EsseReale
Explore the Yo-Go prototype. Rotate it and raise or lower the seat. The lift poses illustrate the mechanism.
Meet Yo-Go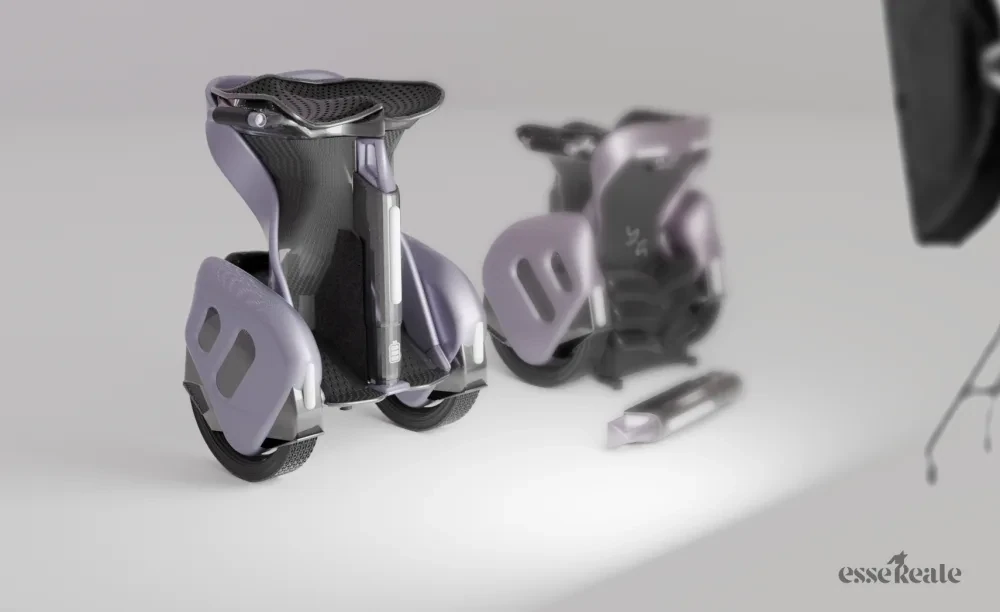 Drag sideways to turn · Yo-Go Mk3.5
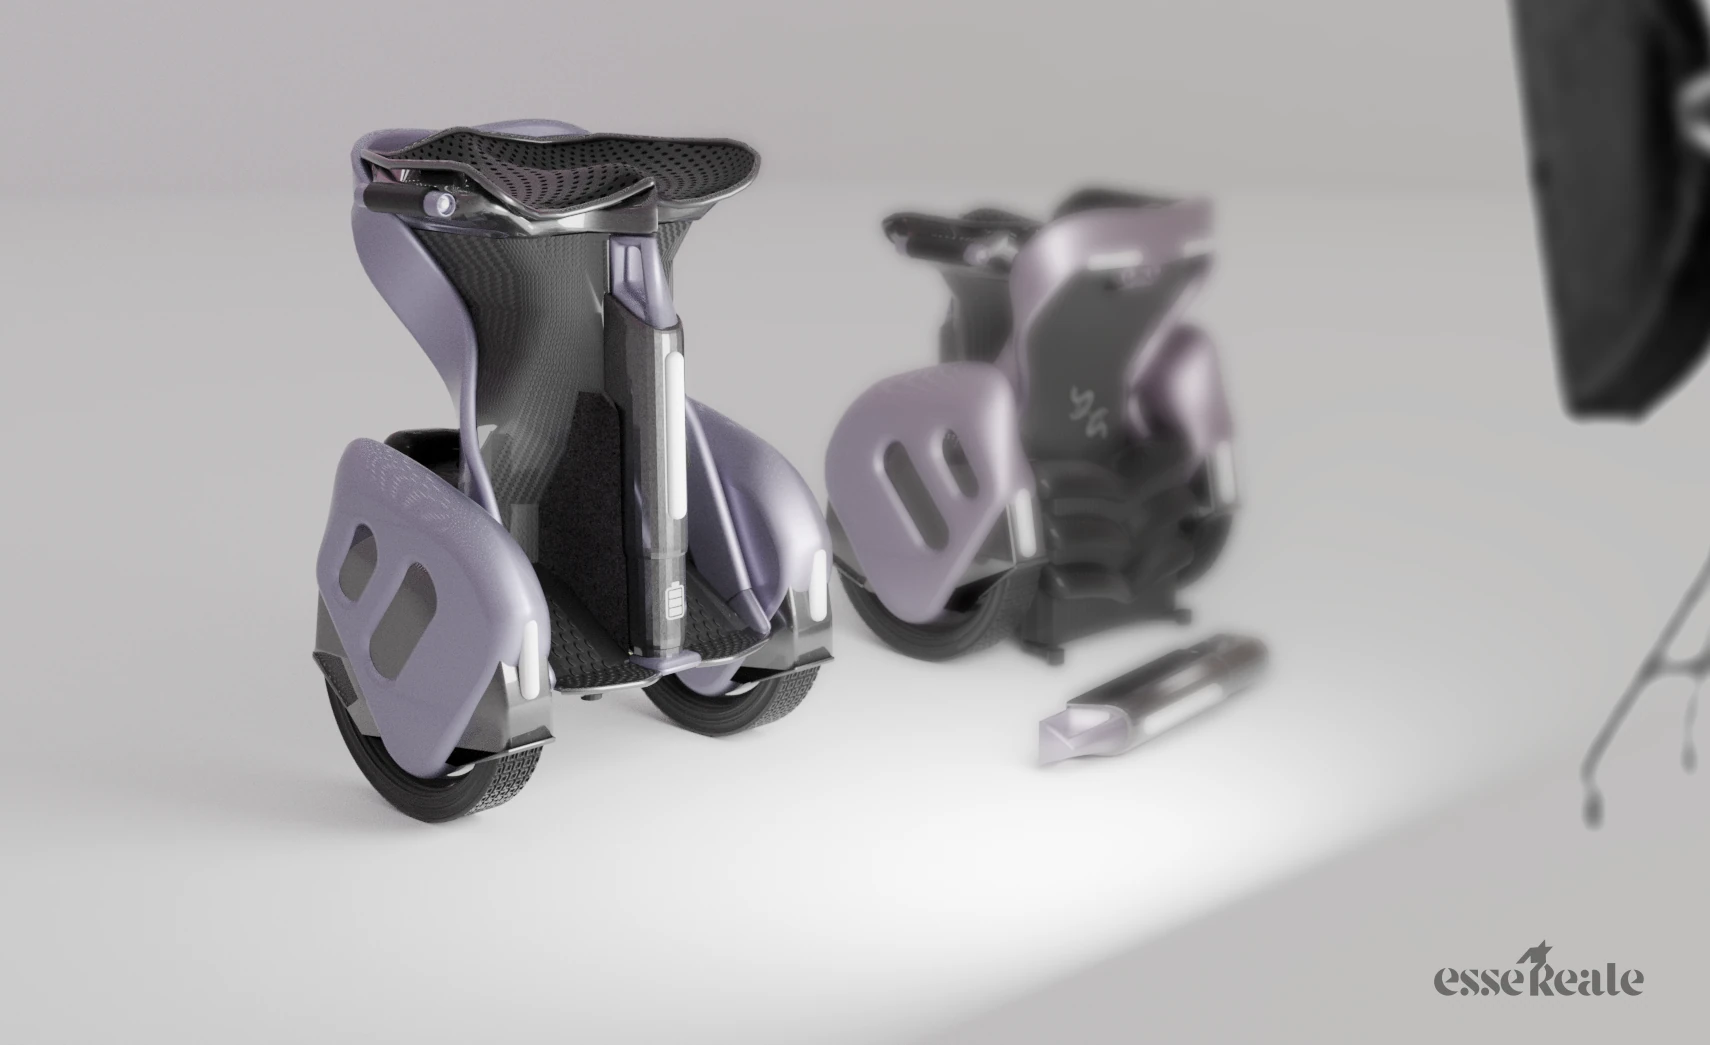
Yo-Go prototype at EsseReale.
As co-founder and CTO at EsseReale, I lead Yo-Go’s technical development across product and mechanical design, electronics, embedded systems, stabilization, control algorithms and software. I also lead our technical team.
Three solver tracks; 36 saved benchmark rows across 12 cases.
Further work: an interactive Pareto-front comparison of the saved benchmark results.
Rule-based placement, mass properties, inertia tensors and external placement rules.
Further work: a 3D layout viewer showing centre of gravity, inertia, collisions and keep-out regions.
Nonlinear models, motor force/torque maps and pseudoinverse allocation code.
Further work: compare actuator-allocation methods under saturation and a defined actuator failure.
Dual-network training artifacts and sequential-convex-programming code.
Further work: evaluate multi-step prediction errors on held-out trajectories and compare normalization choices.
Two-body/three-body solver comparisons, saved trajectories and conservation plots.
Further work: compare solver runtime and numerical error under matched conditions.