Skip to content

St. John's, Newfoundland.

Adeel Ahsan · Robotics consultation

Robotics
consultation
in Canada.

ROS integration. Simulation. Control systems.

Robotics consultation for teams across Canada, based in St. John’s, Newfoundland and Labrador. I help teams model robotic systems, develop control algorithms and connect software with sensors, actuators and existing hardware.

Interactive simulation

Pick. Move. Place.

Loading robot…
Preparing the Panda simulation…
Franka Panda · 7-axis arm
MuJoCo physics

Click to set 1 — Pickup. Drag to rotate the view.

Tool position error— mm
Joint effort— N·m
Adjust point coordinates
Pickup point · centimetres

Set two points. The gripper lifts the cube, carries it across the table, and lets it go.

St. John’s, NewfoundlandCanada-wide · Remote worldwideExplore consultation services

Robotic systems.
A practical way forward.

Bring your robotic prototype, control problem or simulation workflow. We’ll identify what needs to work, review the hardware and data available, and define the models, software and tests needed to move the project forward.

Robotics, simulation & control

Model the system, develop its controller and connect the software interfaces. Agree on the operating conditions and how the result will be tested.

Robotics consultation & ROS integration

Technical assessment, system architecture and software integration for robotic prototypes and research platforms.

Review the control architecture, sensor and actuator interfaces, coordinate frames, communication and logging. Develop ROS interfaces and repeatable tests around the hardware and simulation tools already available to your team. Relevant work includes DJI hardware-in-the-loop integration and the ongoing development of Yo-Go’s stabilization and control systems.

A scoped integration plan, interface software, setup documentation and agreed system tests.

  • ROS
  • Sensors & actuators
  • Control architecture
  • Hardware integration

Nonlinear dynamics & 6-DOF modeling

Vehicle models with propulsion, mass and inertia, actuator dynamics, sensors and environmental disturbances.

Trim operating points, linearize the nonlinear model, examine stability and compare predictions with supplied measurements. Fidelity is evaluated against the data and operating envelope agreed for the project.

Documented plant model, assumptions, analysis and repeatable simulation tests.

  • 6-DOF
  • Trim & linearization
  • MATLAB / Simulink
  • Python

Control design & performance evaluation

Develop and evaluate control algorithms for tracking, disturbance rejection and constrained operation.

Select PID, LQR, MPC / NMPC, gain scheduling or nonlinear control methods around the system’s dynamics and requirements. Compare tracking error and control effort, and check actuator-limit compliance in repeatable simulation or hardware-in-the-loop tests, as agreed for the project.

Controller implementation, baseline comparisons and test reports.

  • PID / LQR
  • MPC / NMPC
  • Disturbance observers
  • Control allocation

Pixhawk, ArduPilot & SITL integration

Connect autopilot software, custom dynamics and ground stations in a reproducible simulation workflow.

ArduPilot, JSBSim and Mission Planner workflows, MATLAB / Simulink or Python plant interfaces, MAVLink communication, parameter experiments and telemetry analysis. Pixhawk hardware integration is scoped to the selected board, firmware and supported interfaces.

Versioned simulation setup, interface code and a repeatable mission test.

  • Pixhawk
  • ArduPilot
  • JSBSim
  • Mission Planner
  • MAVLink

Fixed-wing missions & trajectory optimization

Planning software for coverage, waypoints, loitering and smooth trajectories within vehicle constraints.

Represent turn and bank limits, altitude, wind, terrain clearance and energy reserves as appropriate to the mission. Develop constrained, nonlinear or convex optimization formulations, compare baselines and explain infeasible requests.

Planner or API, constraint checks, solver analysis and mission export.

  • Fixed-wing UAVs
  • Mission planning
  • Numerical optimization
  • Bézier trajectories

Hardware-in-the-loop setup support

Establish HIL workflows around existing flight controllers, companion computers and simulation environments.

Define the architecture, connect supported software interfaces, map signals, check timing, configure telemetry and develop test procedures. The project uses existing equipment; hardware manufacture and physical-product development are outside this service.

Integration software, setup documentation and an agreed test procedure.

  • HIL / SIL
  • ROS
  • Companion computers
  • Timing & logging

Model validation & virtual test automation

Turn logs and simulations into repeatable comparisons, parameter estimates and regression reports.

Align timestamps and coordinate frames, compare model predictions with held-out measurements, estimate parameters and evaluate uncertainty. Automate scenario sweeps, fault cases and Monte Carlo experiments with documented assumptions.

Model-to-log analysis, scenario runner and versioned evidence reports.

  • System identification
  • Monte Carlo
  • Log replay
  • Regression tests

Software & digital products

Take the idea beyond a slide. Build something people can actually use.

Idea to deployed web application

Product scoping, user workflows, interface design and full-stack development through deployment and handover.

Build the agreed workflows with accounts, permissions, persistent data and integrations. Projects can include technical dashboards, research tools, internal applications and customer-facing products, with testing and ongoing support scoped from the start.

Usable deployed application, documented source and a maintenance plan.

  • Product design
  • Frontend & backend
  • Integrations
  • Deployment

FPV & interactive simulation software

Custom flight experiences with joystick or RC input, FPV views, configurable dynamics and mission scenarios.

Develop input calibration, dead zones, rates, flight-mode behavior, replay and performance analysis. Interactive simulations can support demonstrations, research and application-specific practice.

Interactive simulator with documented controls and configurable scenarios.

  • Joystick / RC input
  • FPV cameras
  • Replay
  • Interactive visualization

Scientific software & technical dashboards

Purpose-built analysis applications, optimization APIs and simulation interfaces for technical teams.

Connect models, data and algorithms in MATLAB / Simulink or Python. Develop telemetry dashboards, parameter tools and digital-twin workflows where the real system and available data support them.

Working application or reusable software module, with examples and documentation.

  • Scientific Python
  • MATLAB / Simulink
  • Technical dashboards
  • Data visualization

Product films & technical demonstrations

Clear walkthroughs, feature demonstrations and launch videos that show a product in use.

Plan the story, capture real workflows and combine screen recordings, annotations, motion and editing. Deliver formats suited to a website, a technical presentation or social media.

Edited product demonstration and agreed web or social versions.

  • Product storytelling
  • Screen capture
  • Motion
  • Editing

Robotics consultation across Canada.

Robotics consultation for teams across Canada, based in St. John’s, Newfoundland and Labrador. For Newfoundland and Labrador projects, on-site requirements and travel are discussed during scoping.

Remote consultation is also available for international projects, with scope, time zones and equipment access agreed in advance.

Start with your robot, software stack and the behaviour you need to improve. Request a consultation with preferred times and your time zone; I’ll confirm availability by email.

Engineering case studies

Explore the work behind the services.

Explore simulations, analysis tools and project figures. Each case explains the problem, my contribution, the method and the scope of the results.

DJI M300 hardware-in-the-loop integration diagram07Explore case study

Robotics integration

DJI M300 hardware-in-the-loop testing

Connect ROS, DJI flight hardware and a simulated aircraft response to exercise trajectory-control software before flight testing.

Hardware setup · research footage & logs
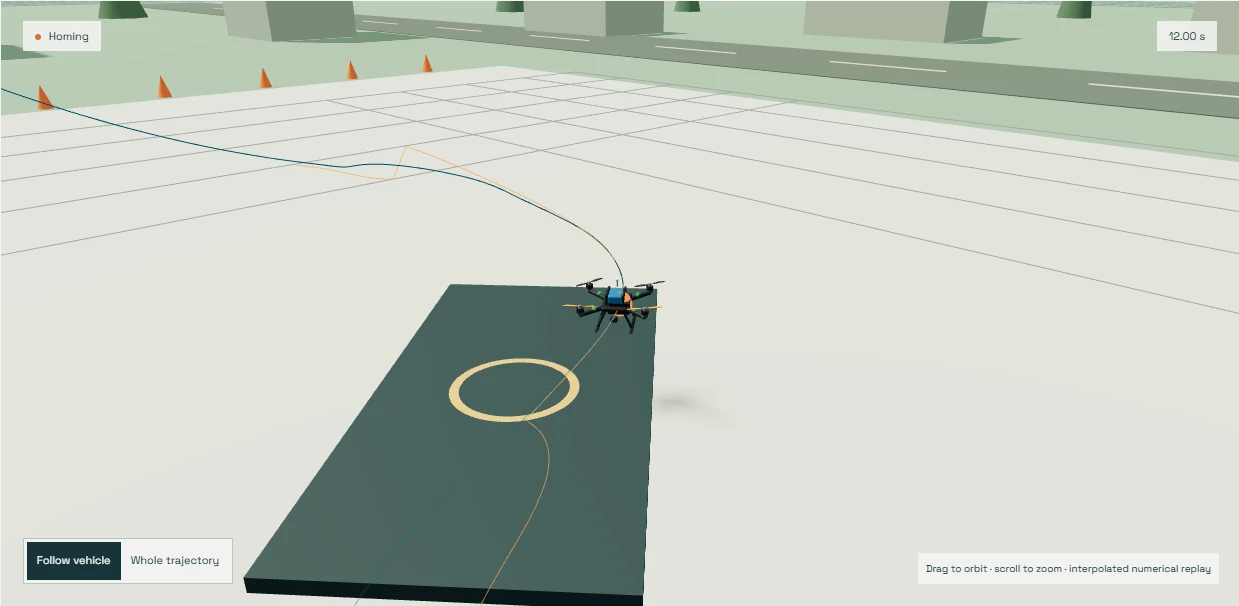
Recorded quadrotor trajectory approaching a moving platform01Explore case study

Guidance & flight control

Moving-platform quadrotor landing

A nonlinear quadrotor simulation tracks a moving platform and transitions from approach to docking. Replay six scenarios alongside the state and control plots.

6 recorded MATLAB simulation scenarios
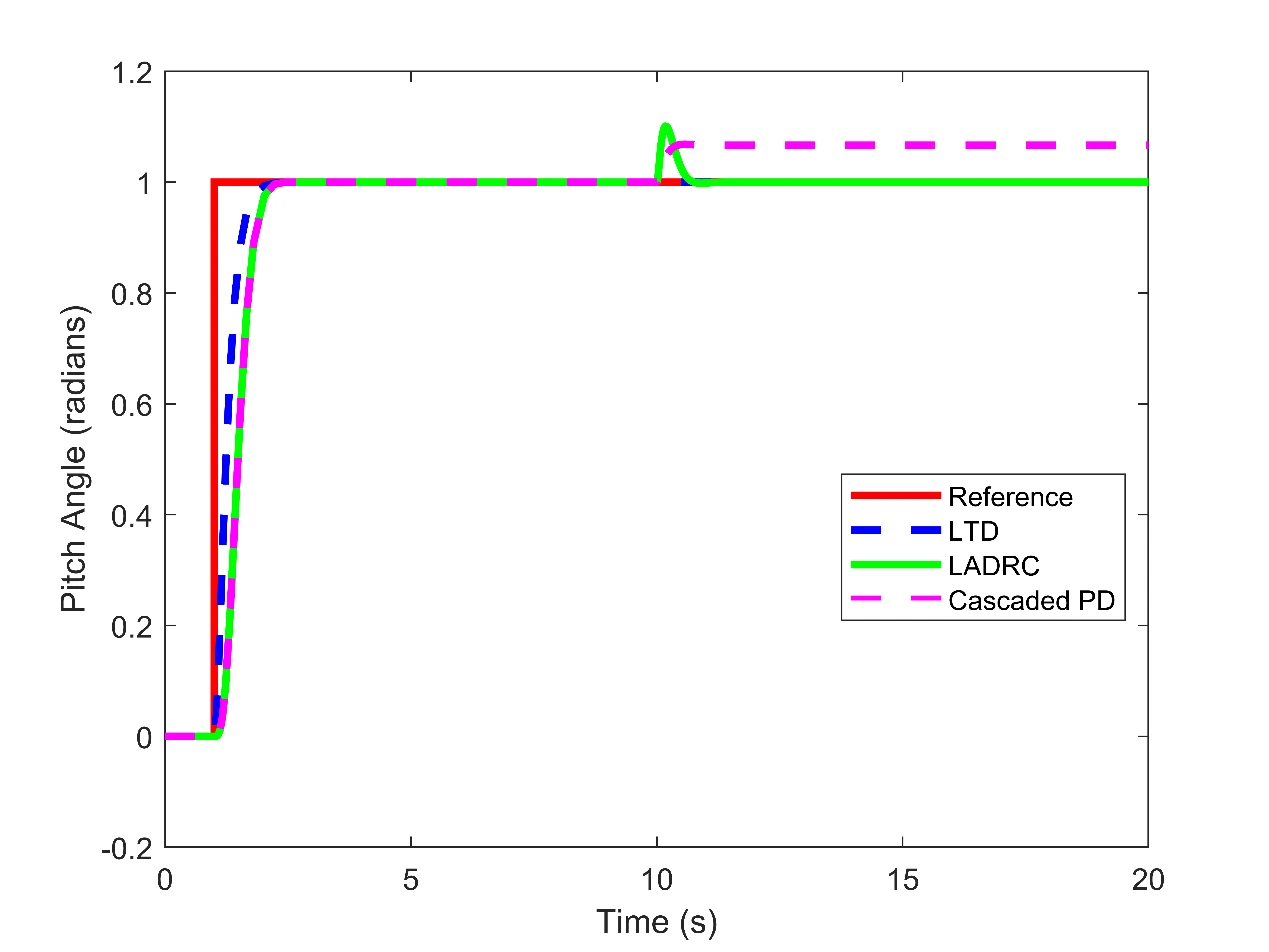
Archived simulated pitch-channel PD and LADRC comparison13Explore case study

Robust control

Quadrotor PD and LADRC control study

A nonlinear quadrotor simulation comparing cascaded PD and linear active disturbance rejection control, from vehicle modelling to discrete controller implementation.

Nonlinear simulation · disturbance tests · MATLAB S-functions
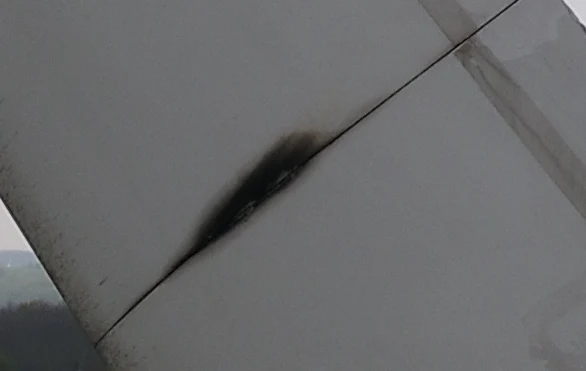
Wind-turbine imagery from the inspection experiment04Explore case study

Machine learning & inspection

Wind-turbine defect detection

A computer-vision workflow for finding candidate defects in turbine imagery, with training metrics, validation figures and an image-by-image prediction explorer.

100 training epochs · saved validation and predictions
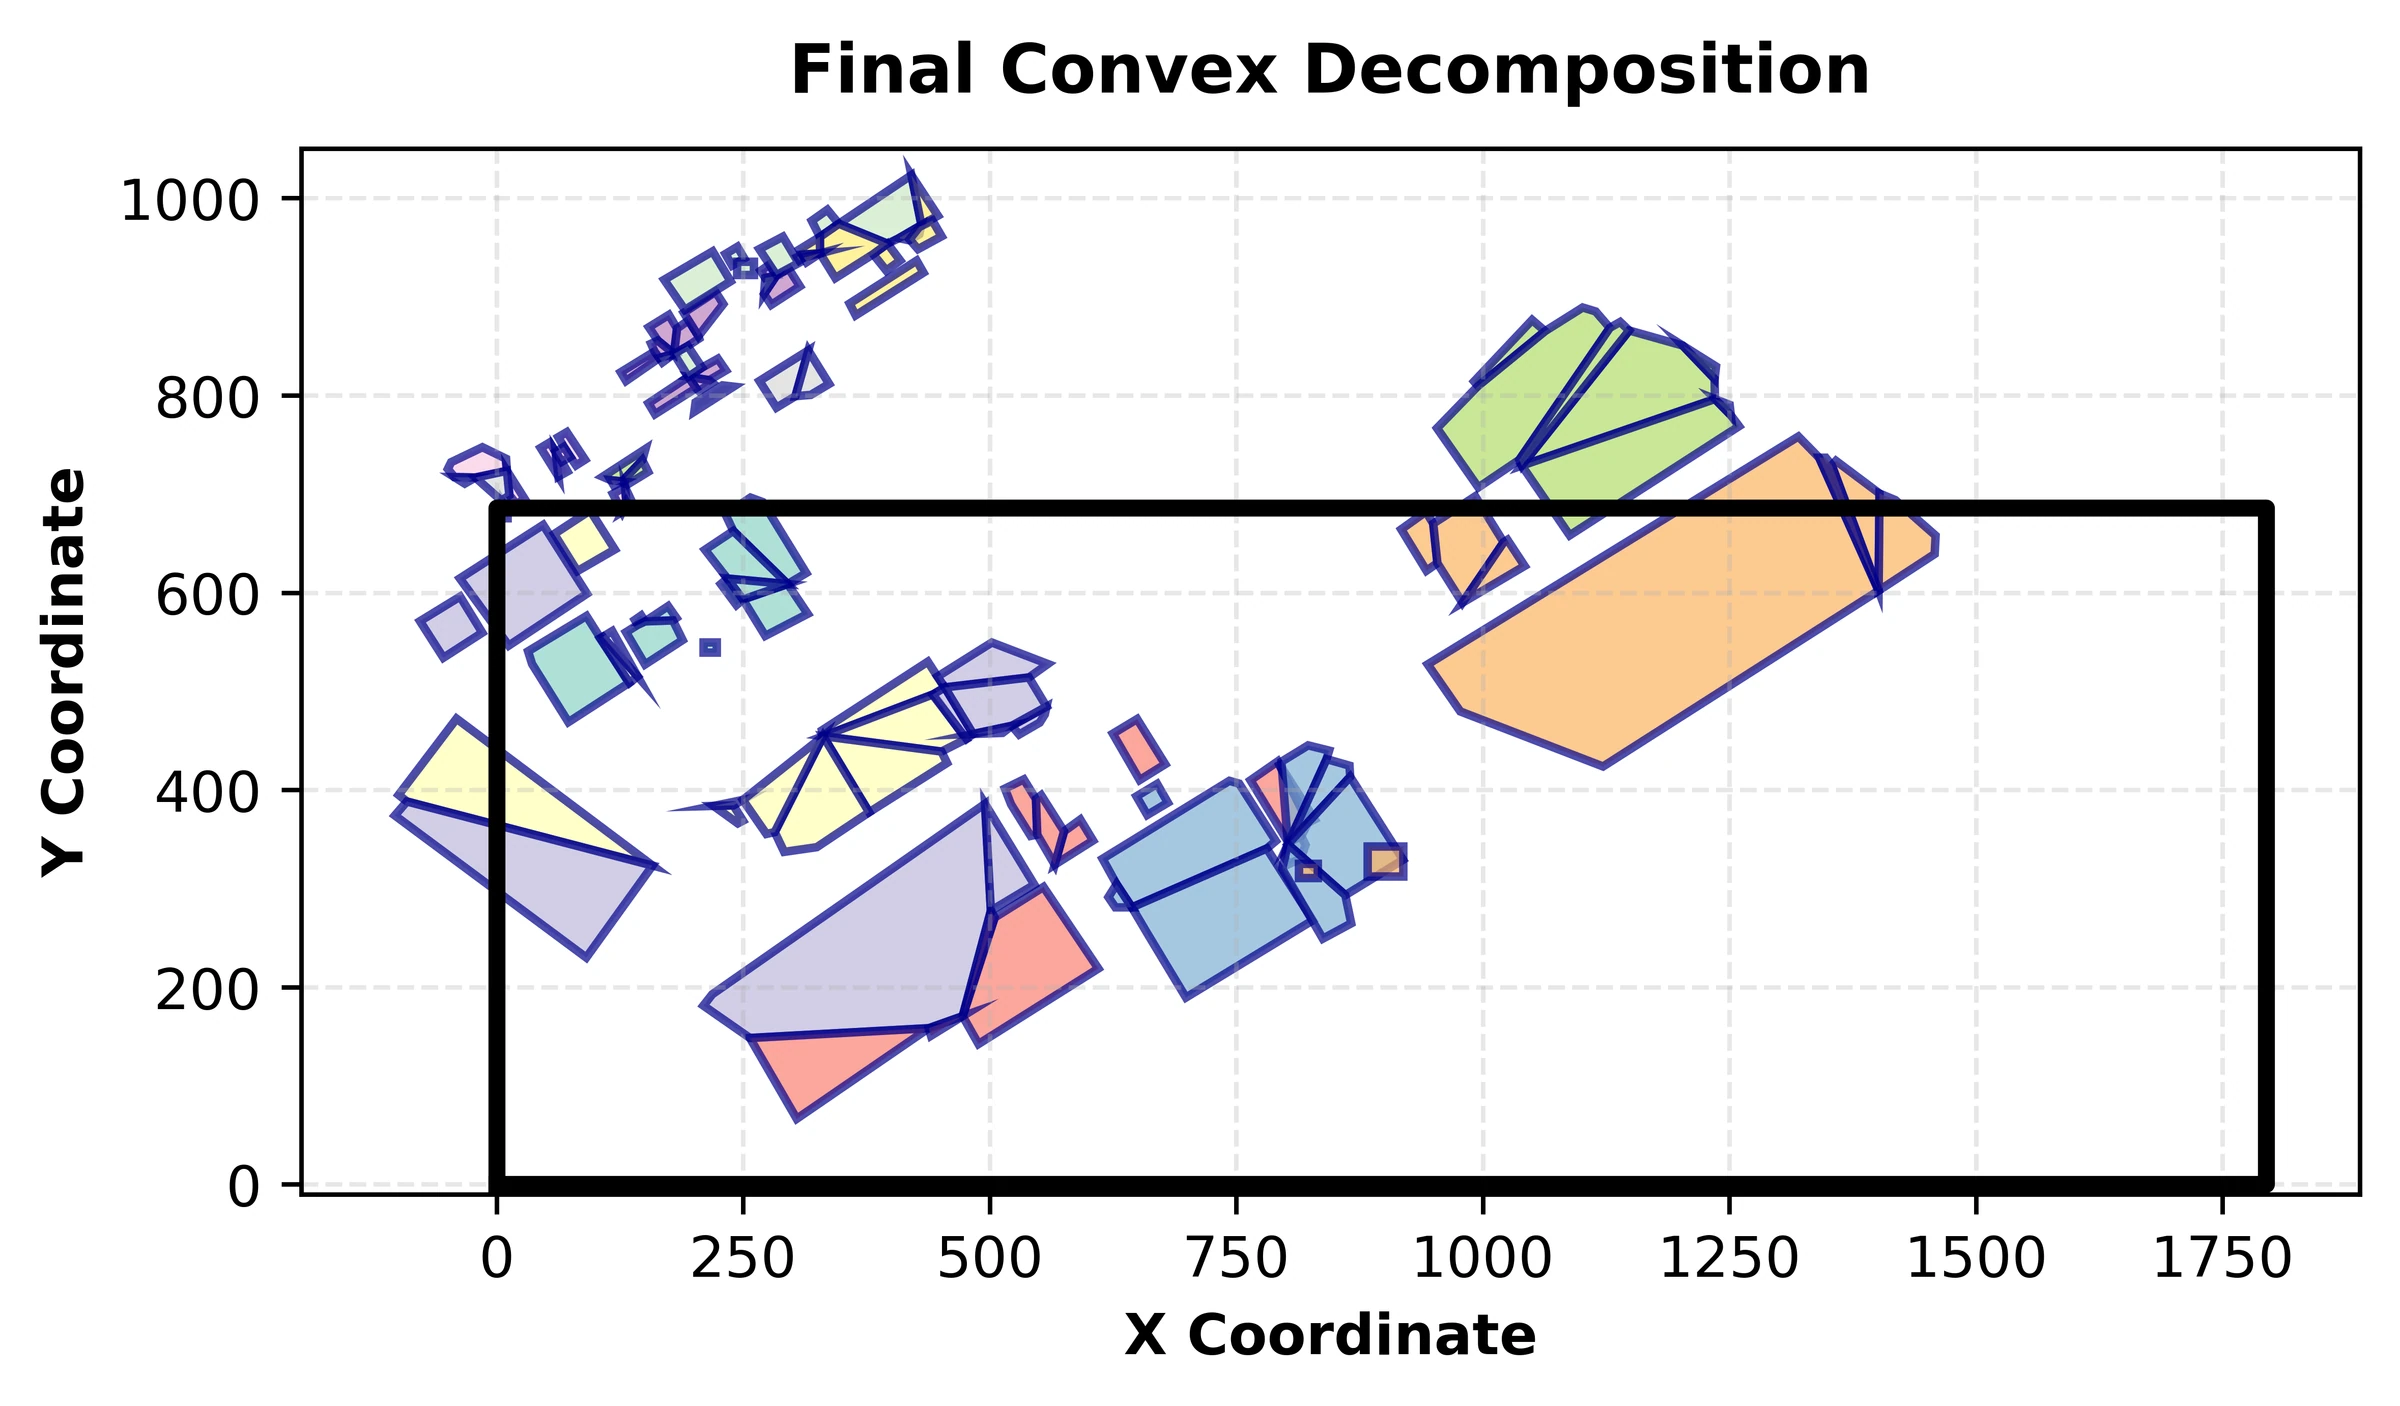
UAV path-planning results with safe corridors06Explore case study

Planning & numerical methods

Obstacle-aware UAV trajectory planning

Turn an obstacle-free route into a smooth trajectory using convex corridors and Bézier curves, with explicit limits on motion.

Research outputs · interactive planner
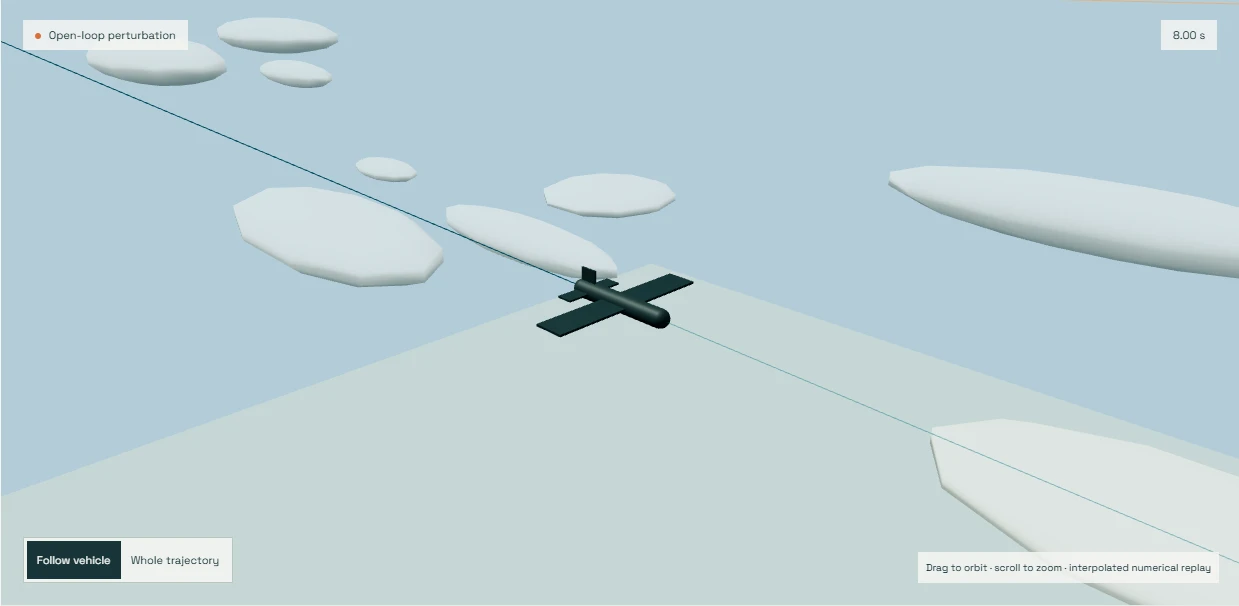
Generic airframe replaying the recorded aircraft perturbation response02Explore case study

Flight dynamics

Aircraft trim and linearization

Find a steady-flight operating point, derive a local linear model and compare its response with the nonlinear aircraft simulation.

MATLAB trim solution · matched linear / nonlinear responses
Explore all 14 engineering case studies

Ideas you can
see in use.

Three different problems. Three working products. Explore the planning software, watch the films, and see how the ideas became usable applications.

Research, made usable

Trajectory Planner

A route through the difficult parts.

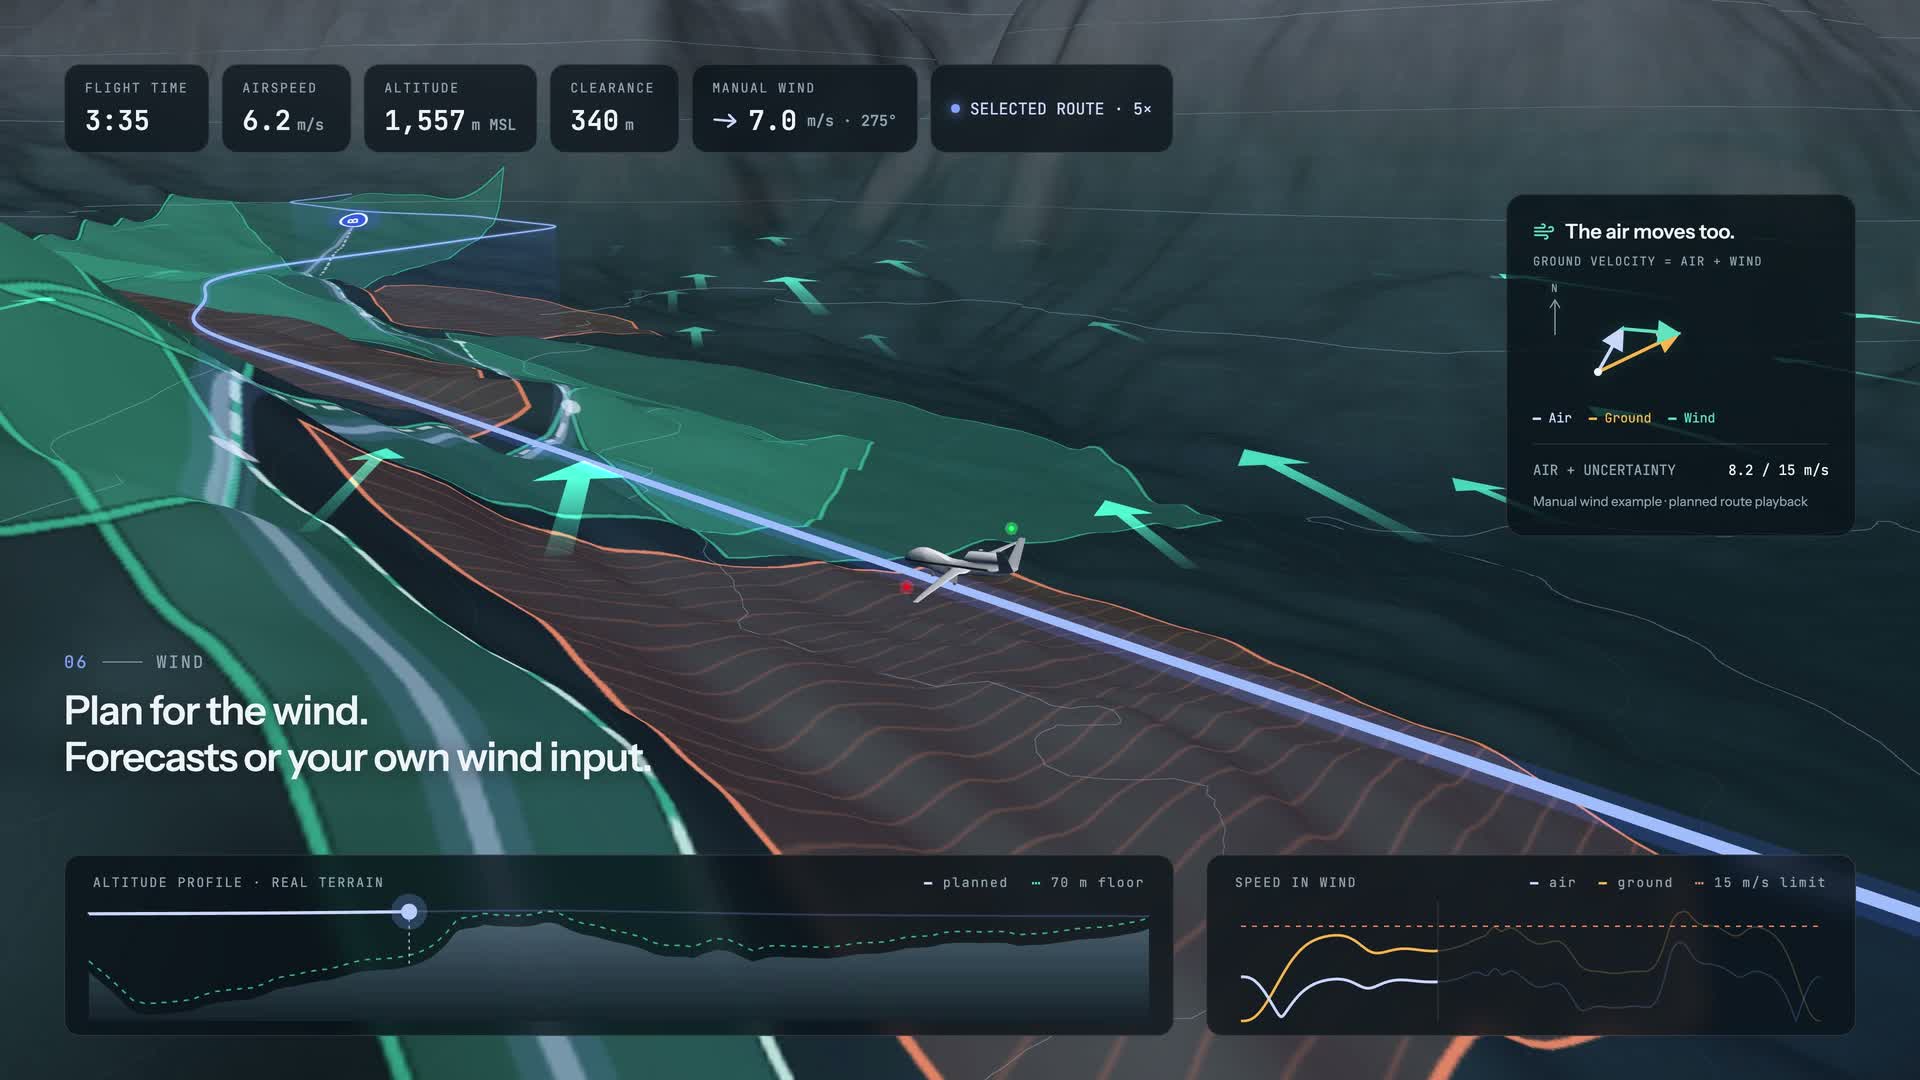
UAV mission planning on 2D and 3D maps. Place waypoints, work around obstacles, review terrain and forecast wind, and inspect a smooth trajectory.

  • Constrained optimization
  • Terrain & mission analysis
  • Saved planning workflows

Live app · Google sign-in
A preview of Trajectory Planner
An idea, built and launched

Fibly

A little more room to think.

Projects, tasks and notes in one workspace. Fibly brings notebooks, focus sessions and an assistant into the everyday work of moving an idea forward.

  • Connected product workflows
  • Notes, projects & focus
  • From concept to deployed app

Live app · Explore the feature demos

fibly

A closer look
at the workspace.

Give the idea a plan.

Turn an outcome into milestones and tasks you can work through.

A preview of Fibly project planning
Customer discovery, connected

Reddiate

Better questions. Clearer ideas.

A workspace for exploring customer problems, reviewing Reddit discussions, organizing interviews and developing a Business Model Canvas around the evidence.

  • Research workflows
  • Interviews & source material
  • Business model planning

Access by request

A preview of Reddiate

From system dynamics
to hardware integration.

Quadrotor control, ROS integration and vehicle modelling underpin my consultation work. Explore the methods, test setups and results in the linked projects.

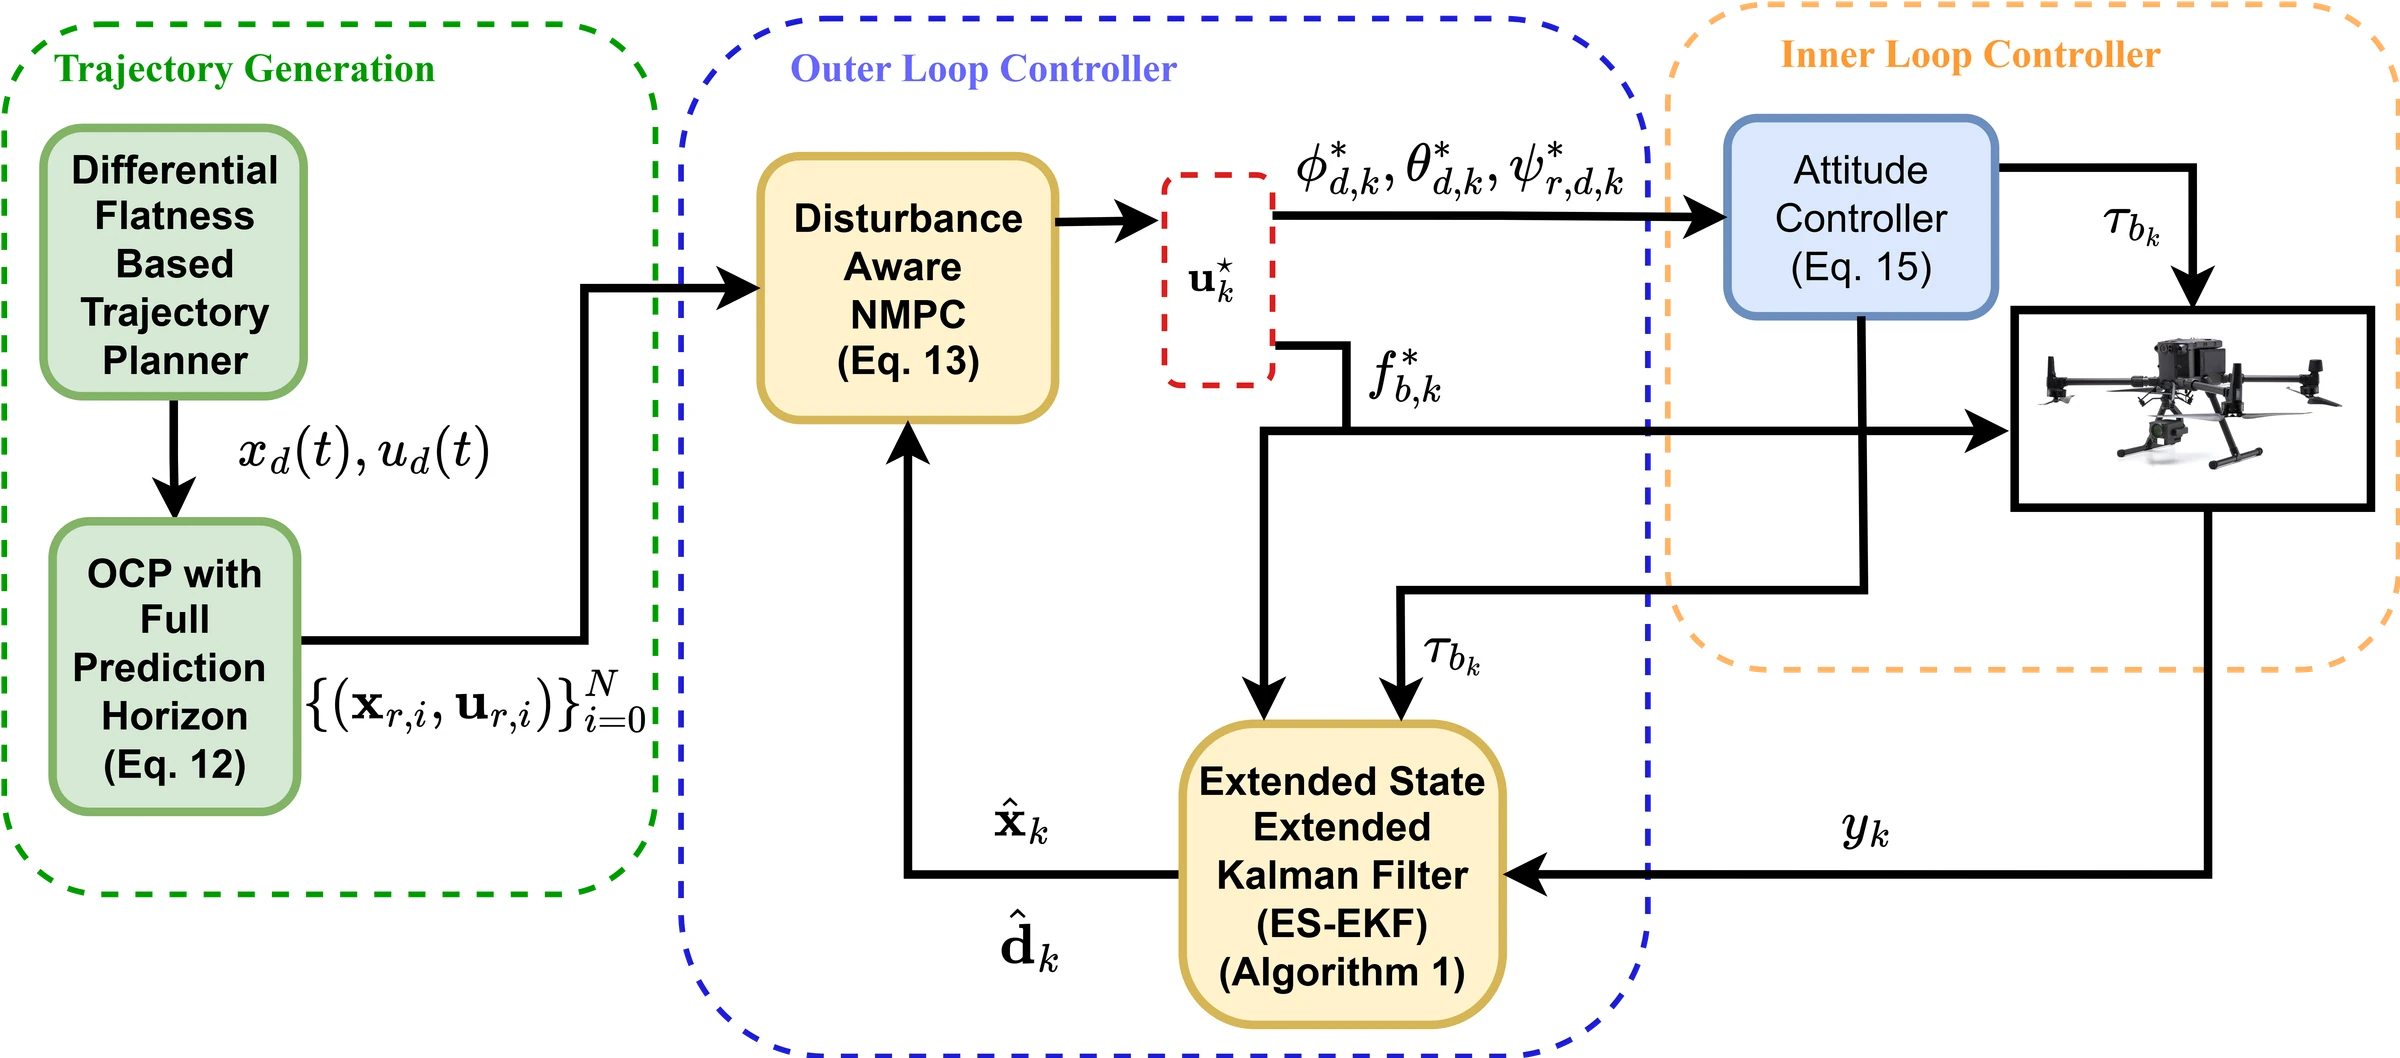
Disturbance observer and nonlinear model predictive control architecture from the quadrotor research
Control research

NMPC that accounts for disturbances.

Geometric disturbance estimation combined with nonlinear model predictive control for a quadrotor. Explore the methods, experiments and stated limits in the paper.

Read the NMPC paper
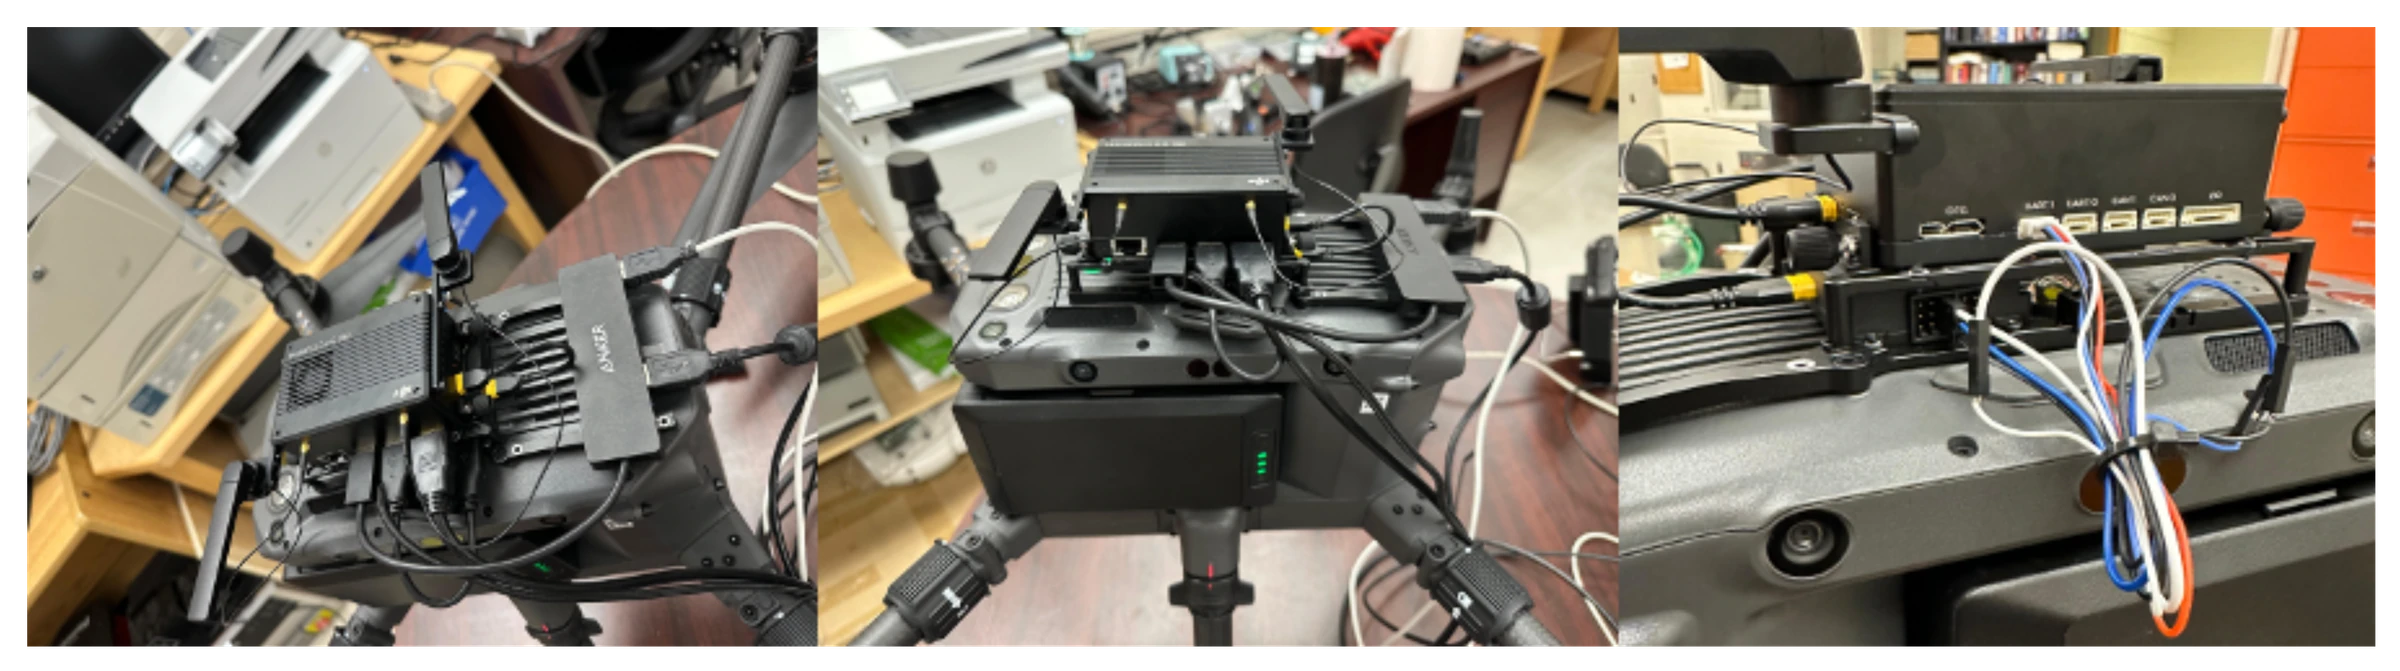
The DJI M300 hardware-in-the-loop research setup
Integration research

Real control hardware.
Simulated aircraft response.

ROS, DJI OSDK and outer-loop PID, LQR and MPC experiments in a DJI M300 HIL setup.

Explore the HIL work

Models with their assumptions attached.

Nonlinear fixed-wing and tilt-rotor models, actuator and sensor dynamics, trimming, linearization and control studies.

Explore modeling projects

Good work is
a conversation.

Client feedback and a former team lead’s recommendation, from my existing portfolio.

View feedback on Upwork

“We have contracted Adeel to advise and guide us on our control architecture design and improvement. He was proficient and diligent. Definitely will hire Adeel again!”

Upwork Client
1 / 17
Read all 17 reviews

“We have contracted Adeel to advise and guide us on our control architecture design and improvement. He was proficient and diligent. Definitely will hire Adeel again!”

Upwork Client

“I knew Adeel as his team lead in the GNC department at Turkish Aerospace. Adeel is a brilliant controls and flight dynamics engineer who has taught himself very advanced control concepts that are well beyond his on-paper degree and years. I tasked Adeel with increasingly advanced projects and he never stopped surprising me by completing them in record time. Having worked with countless engineers, I certainly believe that Adeel is extremely rare and I am sure that he will do great things. He has my strongest recommendation for whatever he does.”

Aseem Islam, Former Lead

“UAV and Missiles Development through learning. Highly recommended!!”

Upwork Client

“Highly recommended! He will do his very best to deliver your project. Listens to all your needs and makes everything perfect. Looking forward to working with him again.”

Upwork Client

“Adeel is a great person and a must-have if you are trying to build anything resembling an aircraft. He has all of the skills that I need.”

Upwork Client

“He is very polite and did all the requirements of the project perfectly.”

Upwork Client

“Adeel was great to work with. Very responsive and thorough communicator and went the extra mile to try and help me solve my problem.”

Upwork Client

“Highly recommended.”

Upwork Client

“He delivered an excellent work. Highly recommended. Very calm and patient and would go extra mile in fulfilling whatever is needed. Will continue to hire him for my future projects.”

Upwork Client

“Muhammad is very patient and cooperative. He's willing to effectively communicate and keep the clients' needs in mind. It has been a pleasure working with him and I will for sure work again.”

Upwork Client

“Muhammad is an absolute pleasure to work with. He never fails to meet the requirements and always goes the extra mile. Once again, he has managed to submit high quality work with very valuable input and discussion.”

Upwork Client

“Muhammad is very respectful and professional. The work done has surpassed my expectations, he really goes the extra mile and provides work that is exactly what you're looking for.”

Upwork Client

“Well done!”

Upwork Client

“Highly recommended, top aerospace engineer! Your input is having a positive impact on the project.”

Upwork Client

“He is an amazing person to work with! This is my second time working with him and I am highly satisfied by the quality of work.”

Upwork Client

“Amazing work! Quick turnaround. Extremely professional and knowledgeable. Definitely would recommend.”

Upwork Client

“Wonderfully talented mathematics specialist who clearly explains solutions under time pressure. Highly recommended.”

Upwork Client

Start with a
good question.

A focused assessment, a defined project or ongoing development support. We agree the scope and fee before the work begins.

Let’s discuss it
  1. 01

    Find the useful outcome.

    Your current system, the problem, available data and the decision the work needs to support.

  2. 02

    Define the work.

    Inputs, deliverables, acceptance criteria, responsibilities, milestones and a clear project fee.

  3. 03

    Build, evaluate, hand over.

    Working software, documented assumptions and repeatable results your team can inspect and use.

A few useful details.

How do I request a robotics consultation?

Use the consultation form on this page or the assistant’s Schedule consultation form. Include your robotics problem, current hardware and software, preferred times and time zone. I review the request and confirm availability by email; submitting a request does not create a confirmed booking.

Can you help with ROS integration and robot control software?

Yes. My work includes ROS interfaces, sensor and actuator integration, control algorithms and simulation workflows. The linked DJI M300 hardware-in-the-loop and control case studies show the relevant setup and methods. Compatibility with your ROS version, hardware, firmware and interfaces is assessed before agreeing the scope.

What robotics consultation can you help with?

I can help assess a control architecture, model system dynamics, develop control algorithms, integrate ROS interfaces and establish simulation or hardware-in-the-loop tests. Bring your hardware details, software stack, available data and the behaviour you need to improve. We’ll define a scope around the parts I can support.

What does an engagement look like?

We begin with the problem, your current setup and the result you need. I then propose a defined scope with inputs, deliverables, acceptance criteria, milestones and a fee. A focused assessment can come before a larger project.

How do you price a project?

Projects are quoted after a technical scoping discussion. Fixed-scope assessments, project milestones and ongoing support are available. Third-party software, compute and any required professional oversight are agreed separately.

Can you help establish a HIL setup?

Yes. I can help define the architecture, develop software interfaces and establish tests around existing equipment. Supported boards, firmware, simulators and responsibilities are agreed before work starts. Hardware manufacture is outside this service.

Do you offer robotics consultation across Canada and internationally?

I’m based in St. John’s, Newfoundland and Labrador, and offer remote robotics consultation across Canada. Remote consultation is also available for international projects. On-site requirements, travel, time zones and access to equipment are agreed during scoping.

How is model fidelity established?

Through stated assumptions, appropriate model detail and comparison with available measurements over an agreed operating envelope. Educational simulations, simulator results and physical test evidence are identified separately. Simulation alone does not establish certification or operational approval.

What about regulated engineering work?

I do not hold a Canadian P.Eng. licence. Project scope and professional responsibility are agreed before engagement.

Get in touch

Request a consultation.

Describe your robot, hardware and software, what needs to improve, and preferred times with your time zone. I’ll confirm availability by email.

Email Adeel