Case 07 / Robotics integration
DJI M300 hardware-in-the-loop testing
Connect ROS, DJI flight hardware and a simulated aircraft response to exercise trajectory-control software before flight testing.
Hardware setup · research footage & logsHow can a controller be exercised through actual flight hardware before moving into flight testing?
I integrated ROS and the DJI Onboard SDK for hardware-in-the-loop controller testing, with trajectory references, logging and analysis. The system diagram, photographs and linked footage show how the controller, simulator and physical flight hardware connect.
Method and workflow
- 01
Connect the system
Link the flight hardware, onboard computer and simulator with a documented signal path.
- 02
Generate references
Use repeatable trajectories and common command limits for the controller study.
- 03
Close the loop
Send controller commands through OSDK and record the resulting states and references.
- 04
Compare carefully
Align timestamps, conditions and metrics before interpreting tracking error or controller trade-offs.
Across the hardware boundary.
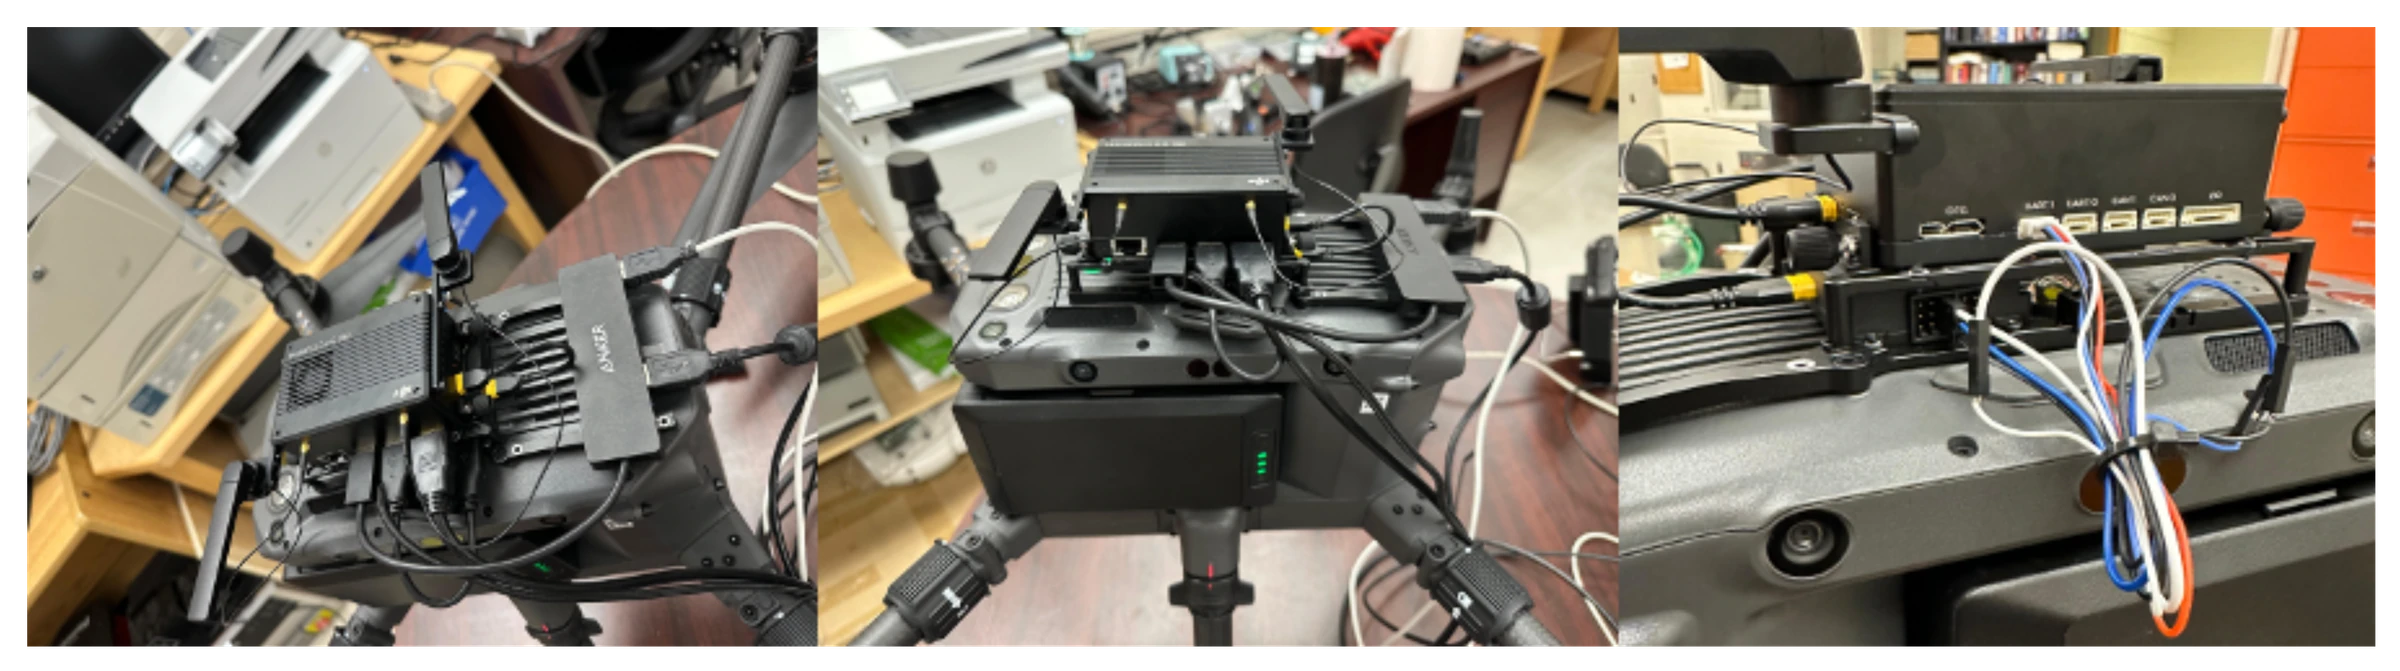
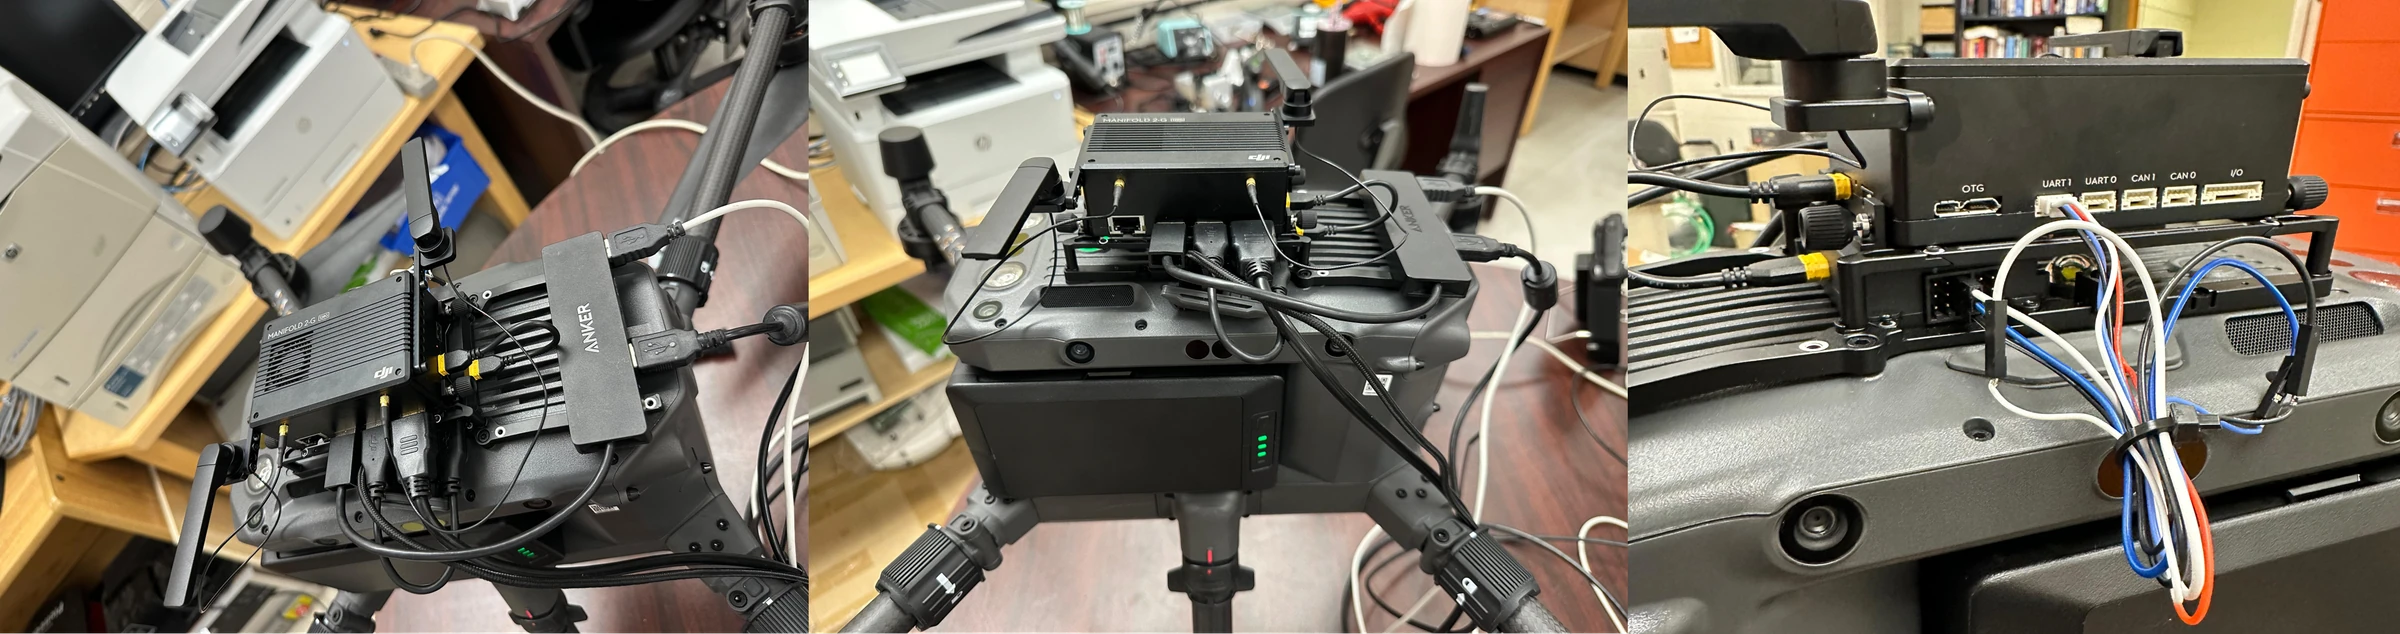
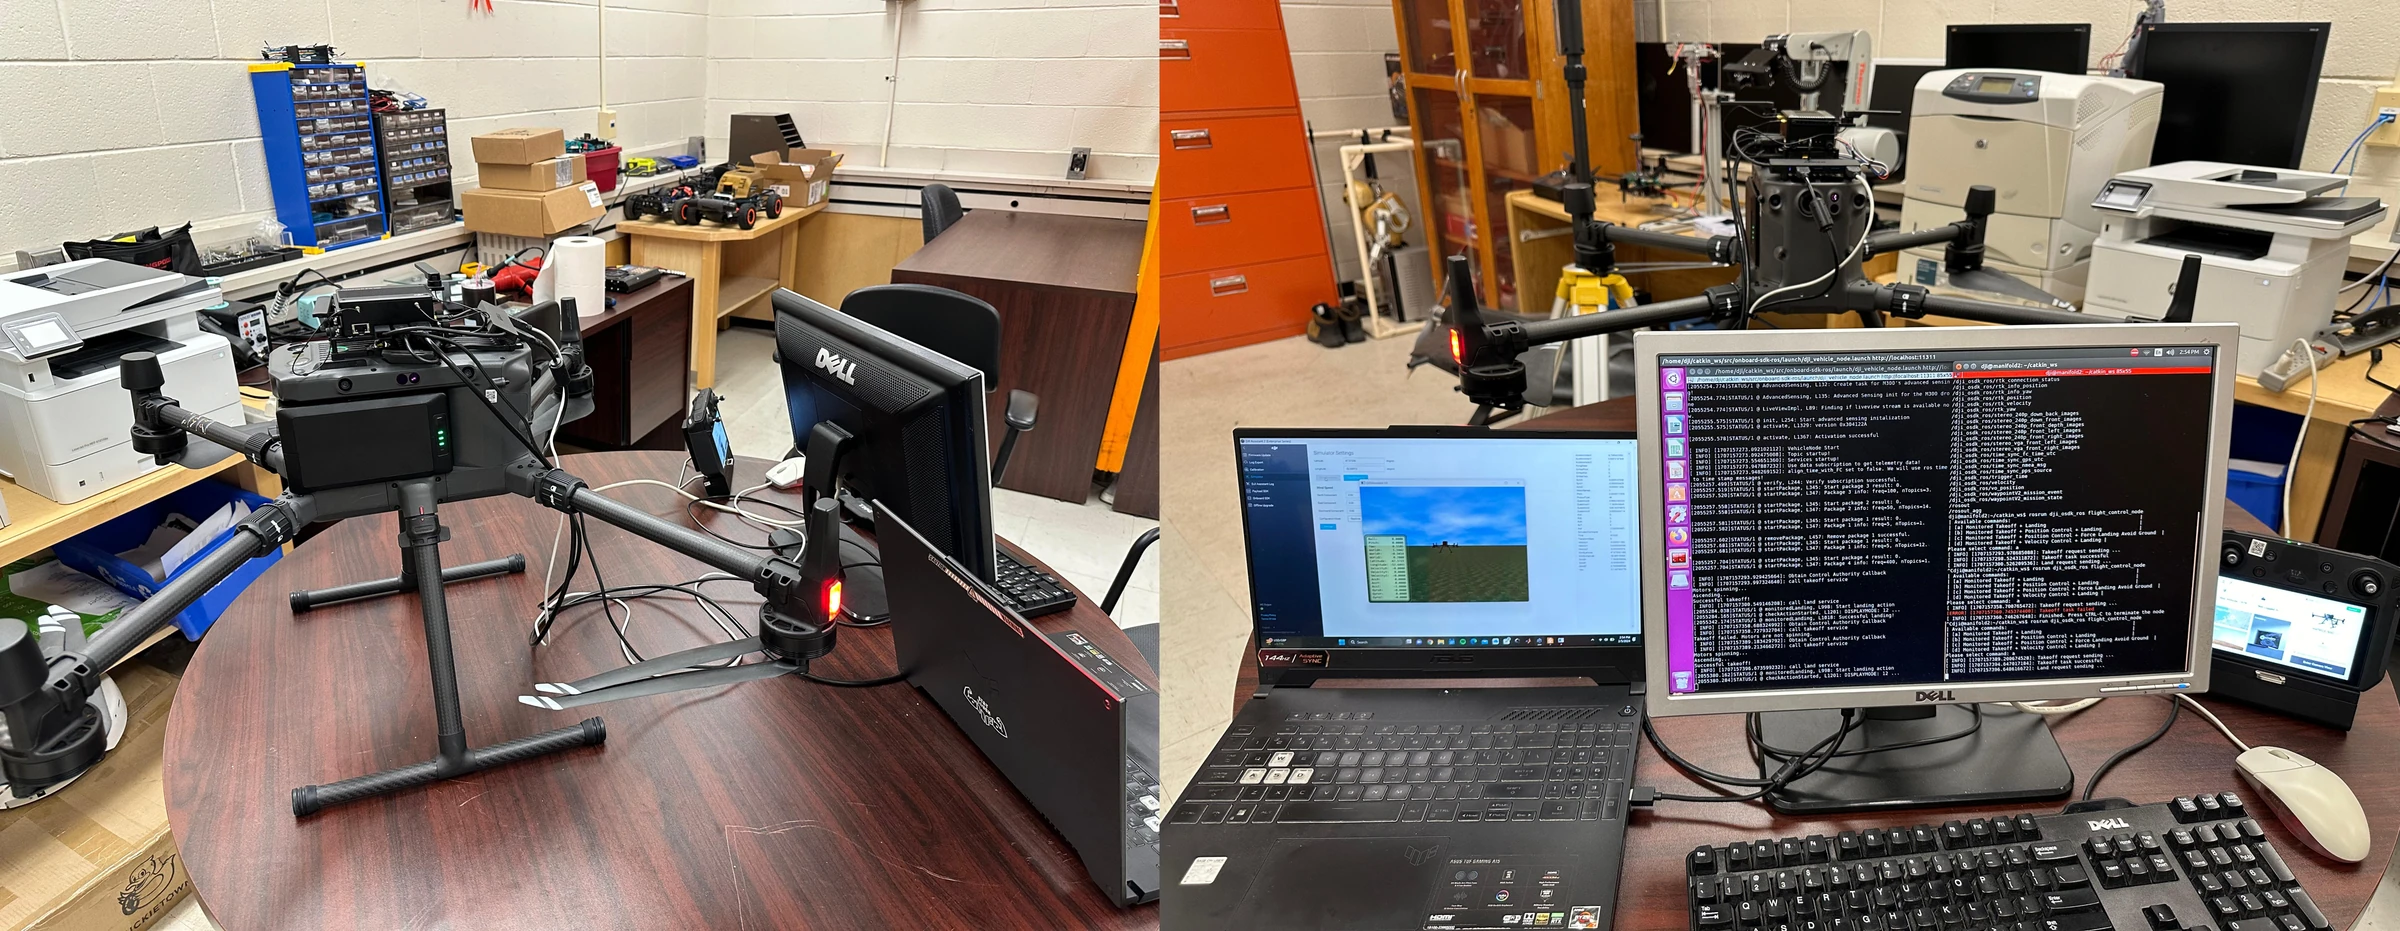
Model assumptions and scope
- Aircraft motion is simulated in these hardware-in-the-loop tests; these results are separate from free-flight experiments.
- A quantitative controller ranking requires matched scenarios, sampling windows and command limits.
Potential extensions
Compare controllers on the same recorded scenarios, with consistent tracking-error metrics and documented timing.
Let’s work through it.
Robotics, simulation and control consultation across Canada, with remote support available internationally. Share your system and the result you need.