Geometric Disturbance Observer Based Nonlinear Model Predictive Control of a Quadrotor
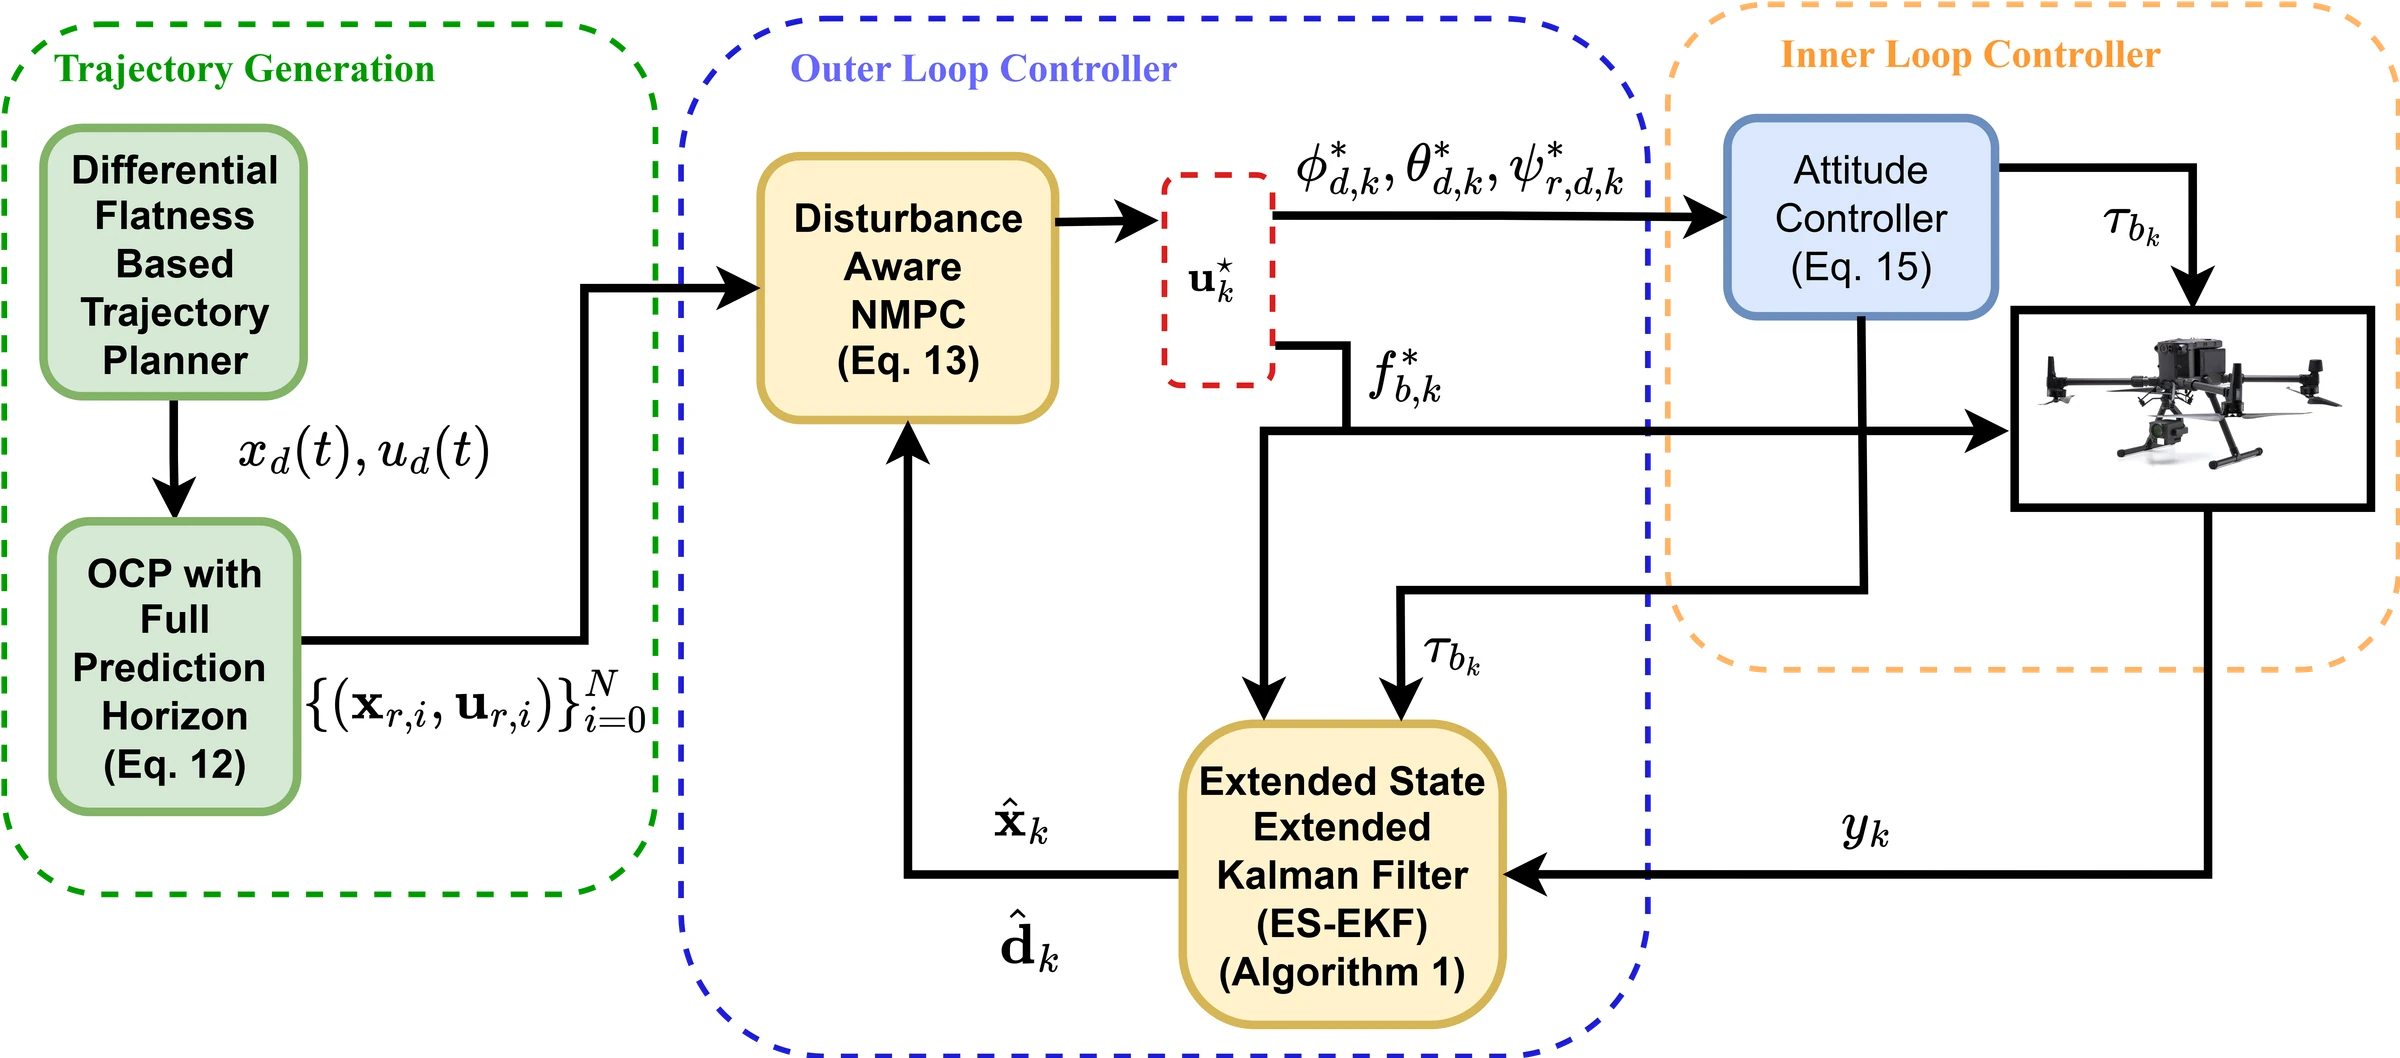
A disturbance observer and nonlinear predictive controller for estimating and compensating for external disturbances acting on a quadrotor.
My papers and theses on UAV flight control, disturbance estimation and trajectory optimization.
Command → response → feedback
A disturbance observer and nonlinear predictive controller for estimating and compensating for external disturbances acting on a quadrotor.
Research archive
My papers and theses on UAV flight control, disturbance estimation and trajectory optimization.
33rd Annual Newfoundland Electrical and Computer Engineering Conference (NECEC 2024), St. John's, NL, Canada
November 14, 2024 (conference presentation)